§W0 WorkDOC WR-SITE-03 · REV 2026-11
Case file · customer names withheld
Different floors. The same habit: measure, fix, hand over.
Every case below comes from a delivered project, a registered patent or a published field test. Each one lists the equipment involved, so you can match it to your own floor.
§W-US United StatesMichigan · California · 2026
In the U.S.: a controller license in Michigan, a field test in California.
Delivered by the same engineers who build the stack.
| Where | What |
|---|---|
| Michigan · 2026 | An automotive parts company licensed our W-RC robot control software to develop and operate its own robot systems. Perpetual license with 12 months of remote support. |
| San Francisco Bay Area · Oct 2026 | Four-day field test on a robotics company's commercial 7-axis arm: 77% less path error with our real-time layer on a Jetson. Case 03 → |
§W1 Case 01Aluminum die-cast parts manufacturer · Korea · 2024–2026
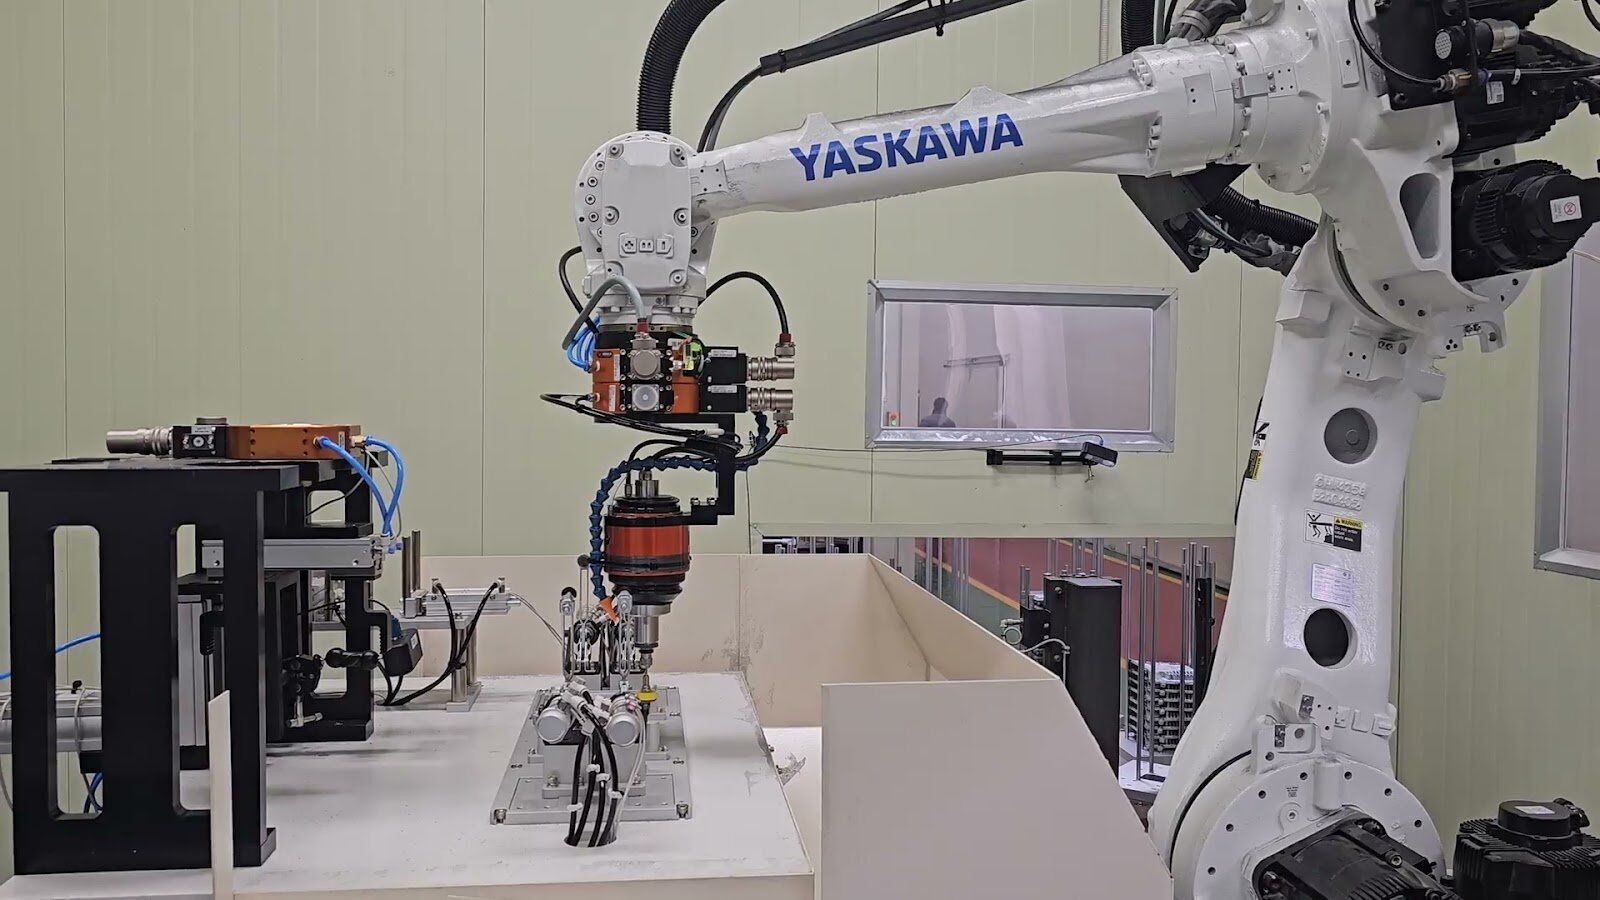
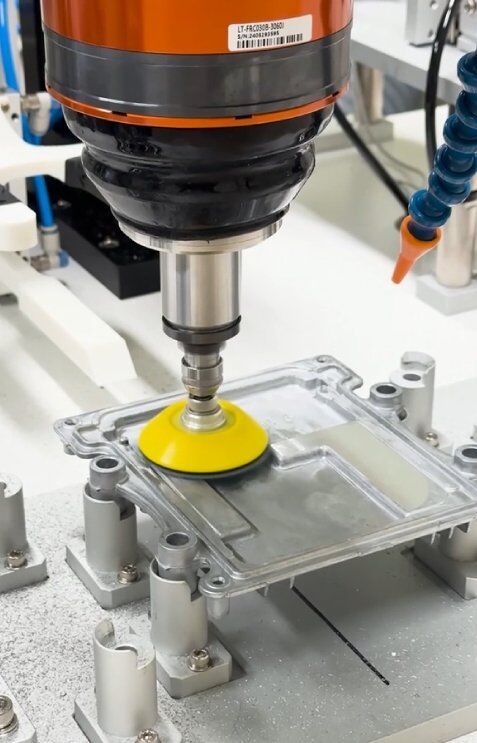
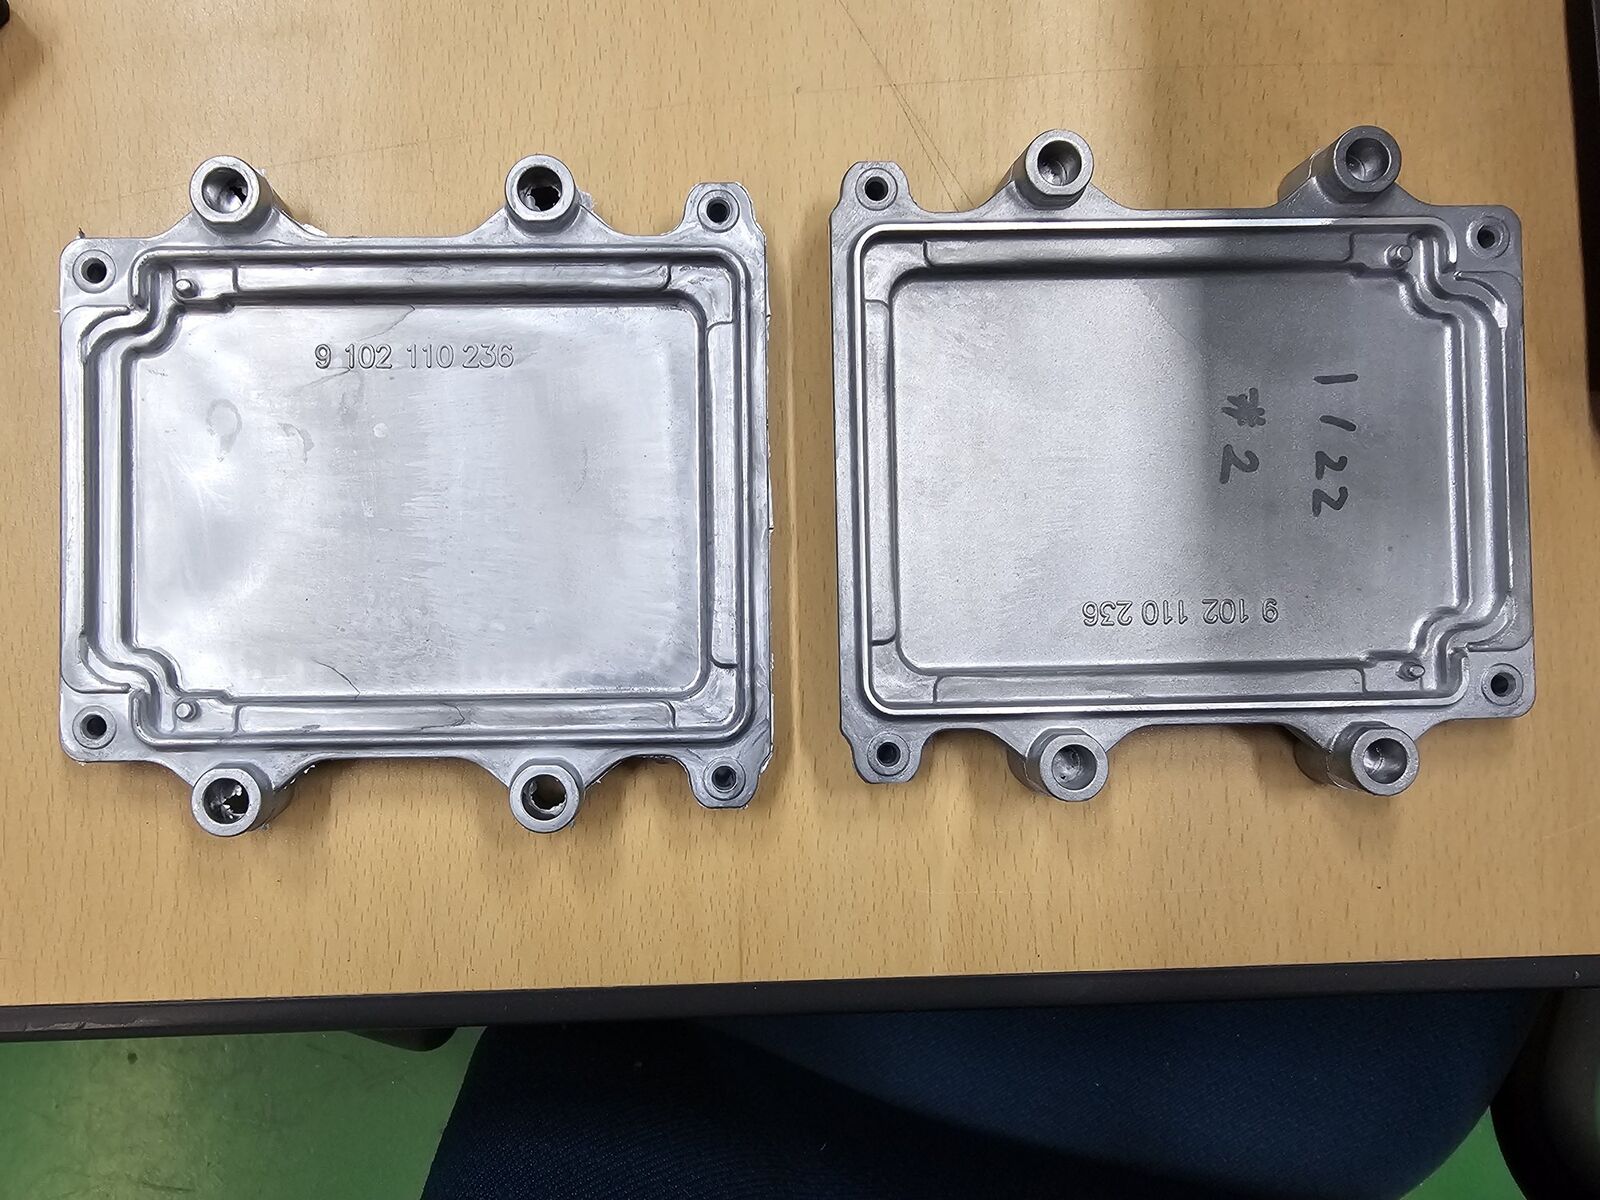
Three years of continuous work on one machining line
- Situation
- A die-cast line (melting, machining, deburring) where parts, jigs and process targets keep changing.
- What blocked production
- Manual deburring, jigs that did not survive model changes, process data nobody trusted.
- What we did
- A robotic deburring cell planned in simulation, with paths generated by a GPU motion planner and streamed to the customer's existing Yaskawa DX200 through a MotoROS2 proxy past its 200-point limit. Vision jigs, grippers and part feeders reworked as parts changed. Furnace, coolant and thermal-camera sensors with data acquisition, PID tuning and PLC fixes.
- Result
- Repeat orders in 2024, 2025 and 2026.
- Equipment
- Yaskawa DX200 · MotoROS2 · vision jigs · pneumatic tool changer · PLC
§W2 Case 023PL export logistics center · Korea · 2024–2026
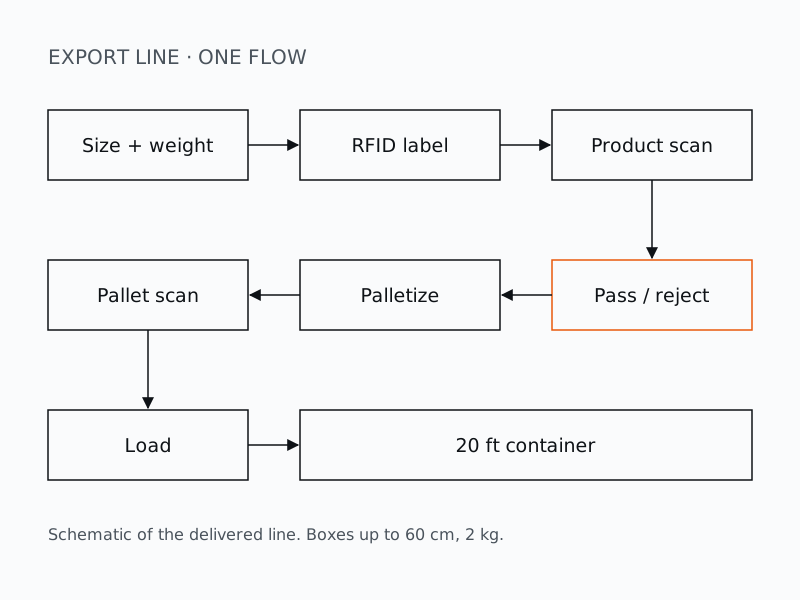
An export line from scan to container
- Situation
- Small cosmetics and apparel boxes for export had to be measured, labelled, checked and loaded in one continuous flow.
- What we did
- One line: conveyor dimension-and-weight check, RFID auto-labelling, product scan gate, pass/reject diverter, palletizing, pallet scan gate and loading into a 20 ft container. Designed, built and delivered by WIM, followed by a second development phase.
- Result
- Delivered in 2026; performance certificate issued by the customer.
- Equipment
- DWS · RFID labeller · scan gates · diverter · palletizer
§W3 Case 03Robotics company · San Francisco Bay Area · field test · Oct 2026
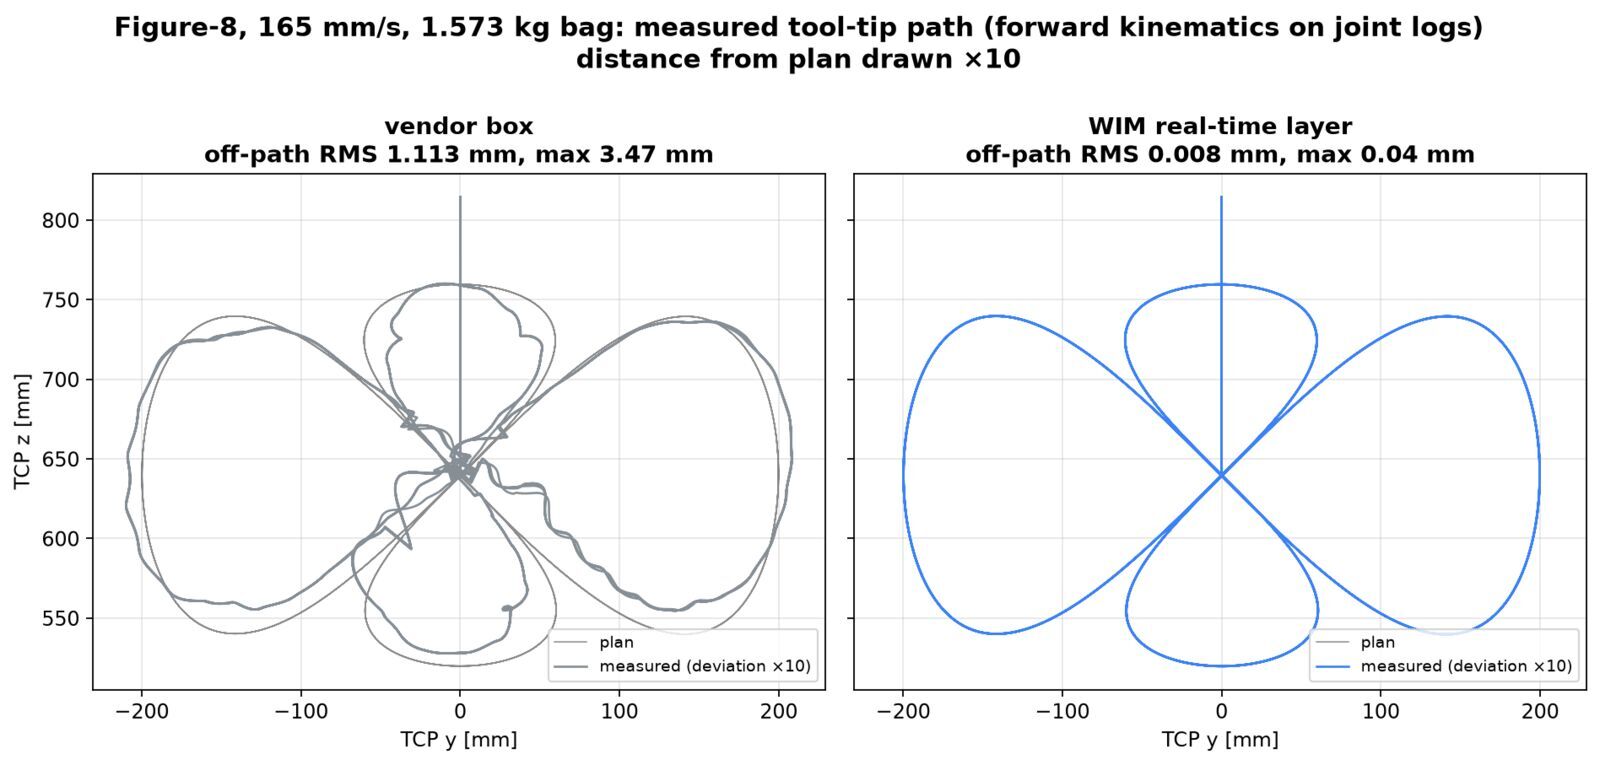
77% less path error on an arm we didn't build.
A robotics company's 7-axis arm lagged and chattered under streamed commands. We put a hard real-time layer on a Jetson in front of the unmodified arm and measured on site for four days.
FIG W3 · Tool-tip path error, RMSmm · same host · lower is better
CH2 naive streamingCH1 WIM real-time layer
SOURCE Engineering blog, "Time is a control input", 2026-10-23, with raw plots.
- Arm
- Commercial 7-axis collaborative arm, unmodified, with F/T sensor, gripper and a 1.57 kg swinging load
- Host
- Jetson AGX Orin, PREEMPT_RT, one isolated CPU at SCHED_FIFO 80; isolated CPU wake-up max 5 µs
- Method
- Joint streaming at 250 Hz, feed-forward on the measured loop delay (6.17–6.96 ms over 14 sine sweeps), S-curve shaping
- Against the built-in planner
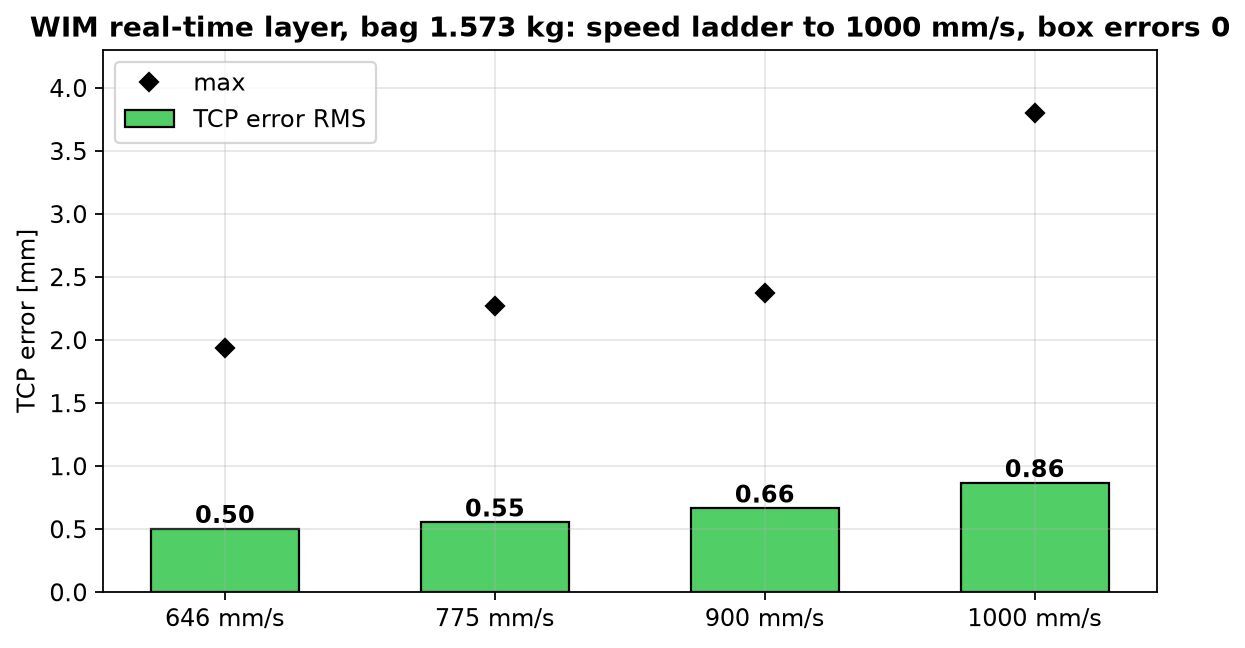
- 1.57 s behind plan → on time · 30 runs, zero controller errors
- Production run
- 21,591 cycles, wake-up lateness p99 0 µs
§W4 Case 04Logistics customer · Japan · 2025
Size, weight and barcode in one pass
- Situation
- A logistics operator needed parcel dimensions, weight and identity captured together at line speed.
- What we did
- Vision logistics software that measures size, reads the barcode and pairs both with the weight in a single pass.
- Result
- Software delivered in 2025 under a licensing and support agreement.
§W5 Case 05Recycling line · Korea · 2023–2025
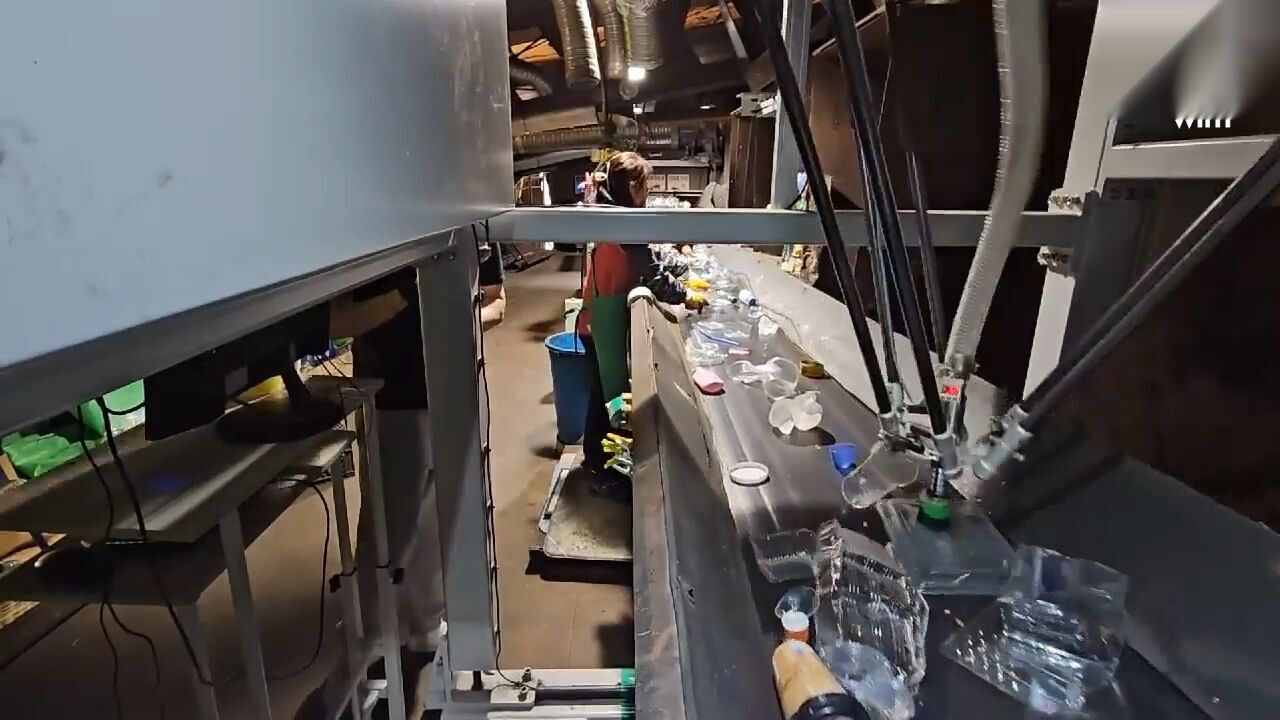
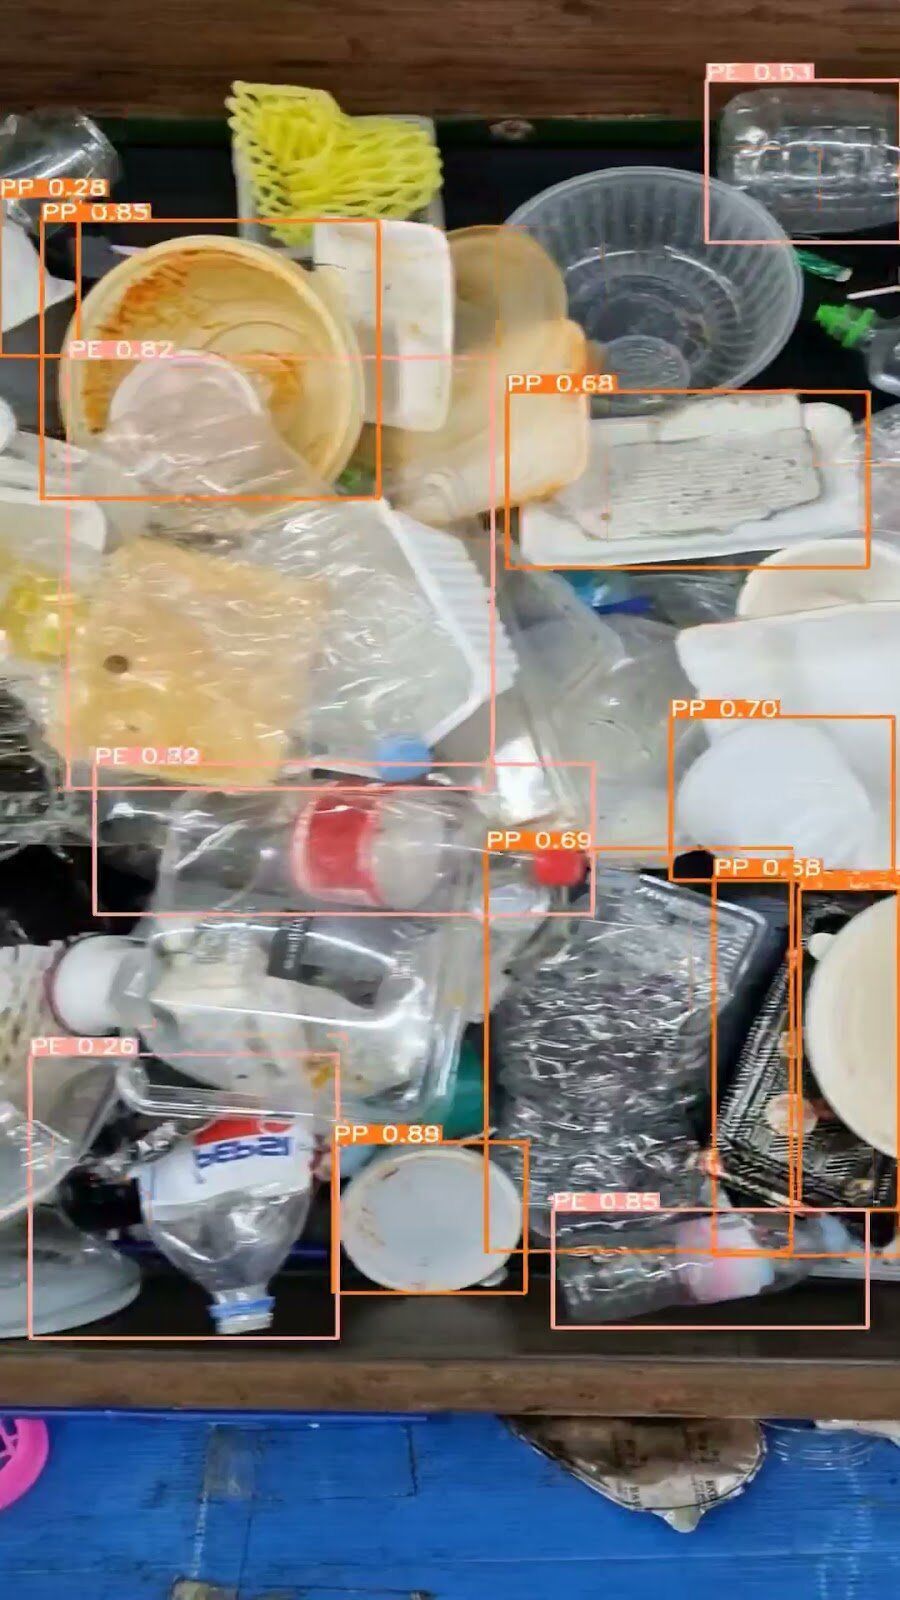
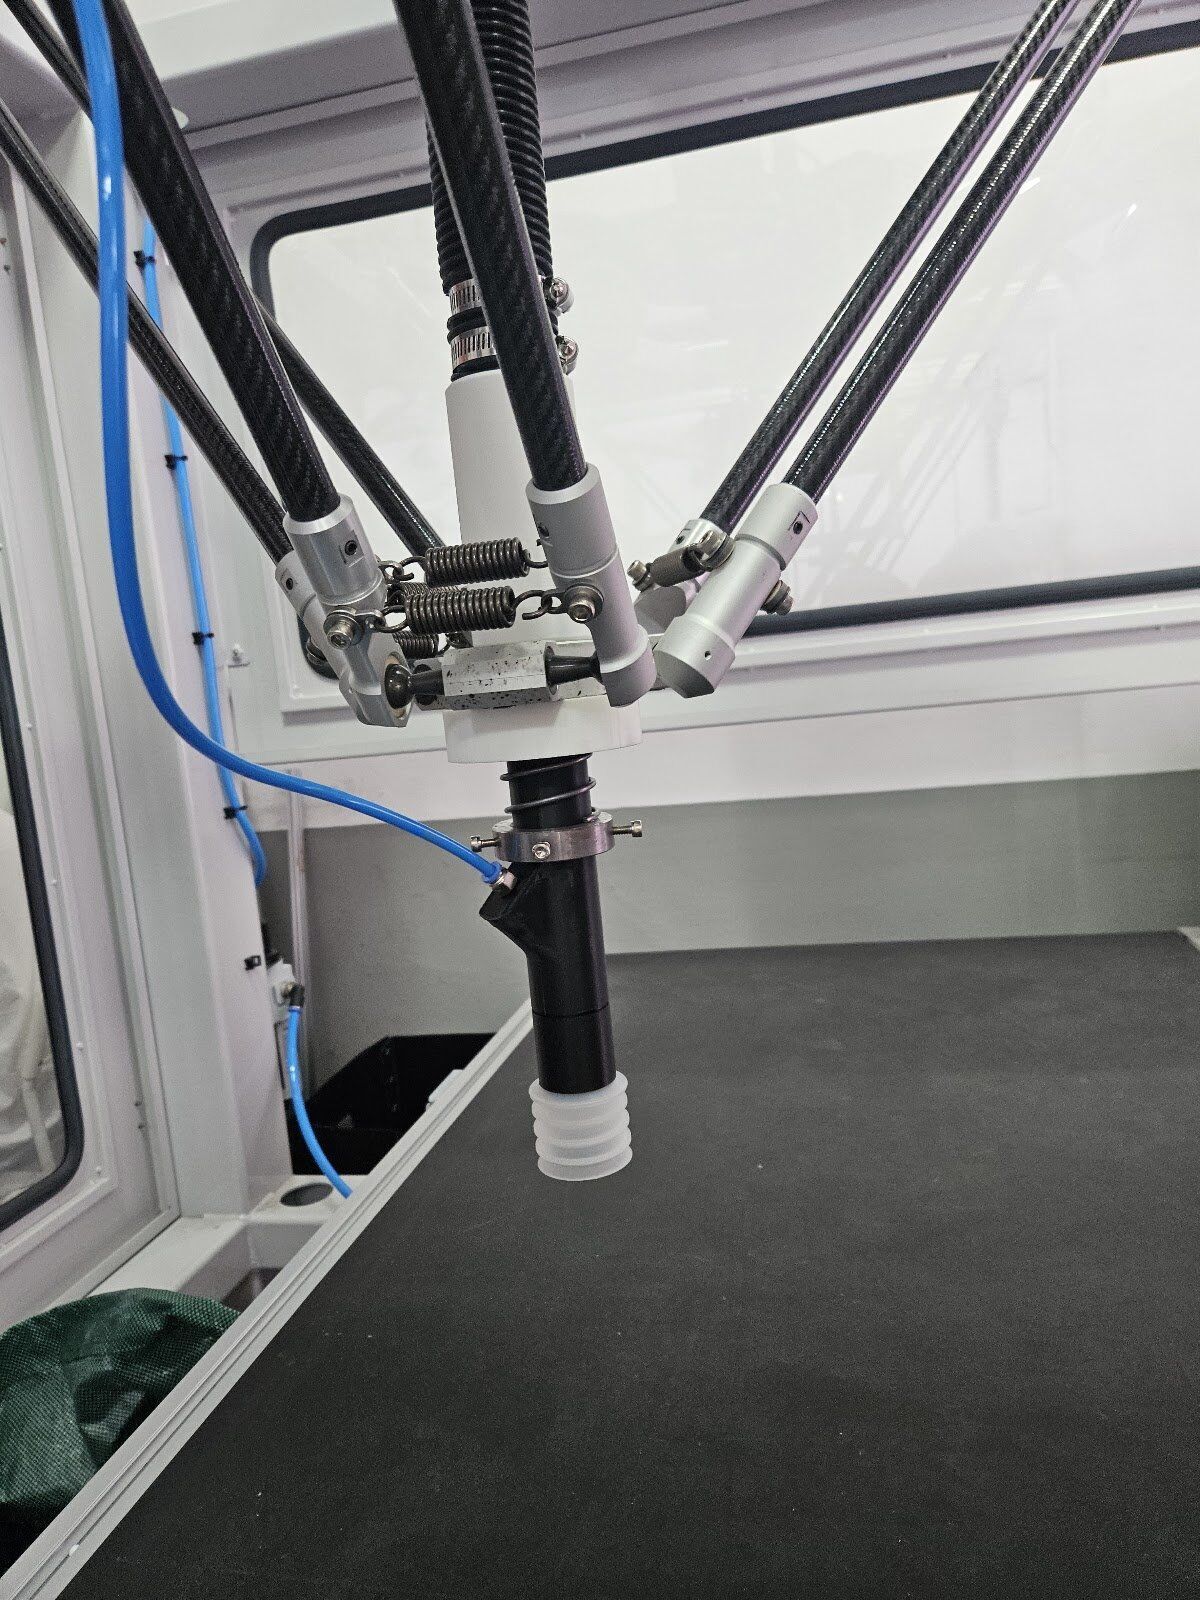
Vision-guided sorting at conveyor speed
- Situation
- Mixed recyclables arrive at 0.5 m/s and have to be picked by type within a 50 ms budget.
- What we did
- Delta-type sorting robots with object detection and speed estimation, so the picker meets each item where it will be, not where it was. Detection rebuilt with TensorRT FP16 and DeepStream on Jetson.
- Result
- First line running in 2023; robotic sorters then delivered to a national research institute in two stages (2024, 2025). On the line, detection went from 15 to 7 ms per frame (67 → 142 FPS) with accuracy 99.2% → 99.1%. Two Korean patents registered on the sorting device.
- Evidence
- KR 10-2729148 · KR 10-2717166 · blog 2024-01-18
§W6 Also deliveredKorea · 2024–2026
Controllers and systems running at 30+ sites.
Product deliveries to companies, national institutes and universities. Item names only.
| Year | Delivered |
|---|---|
| 2026 | Integrated controller for a multi-axis industrial robot cell |
| 2026 | Welding-system controller and components |
| 2026 | Dual-arm robot system for teleoperation |
| 2026 | AMR-to-equipment interlock I/O module |
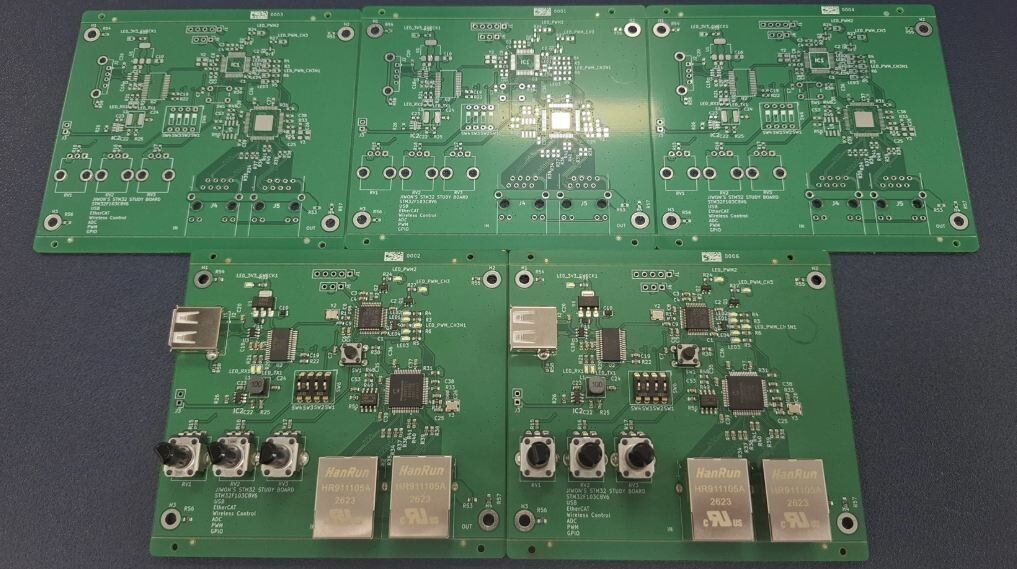
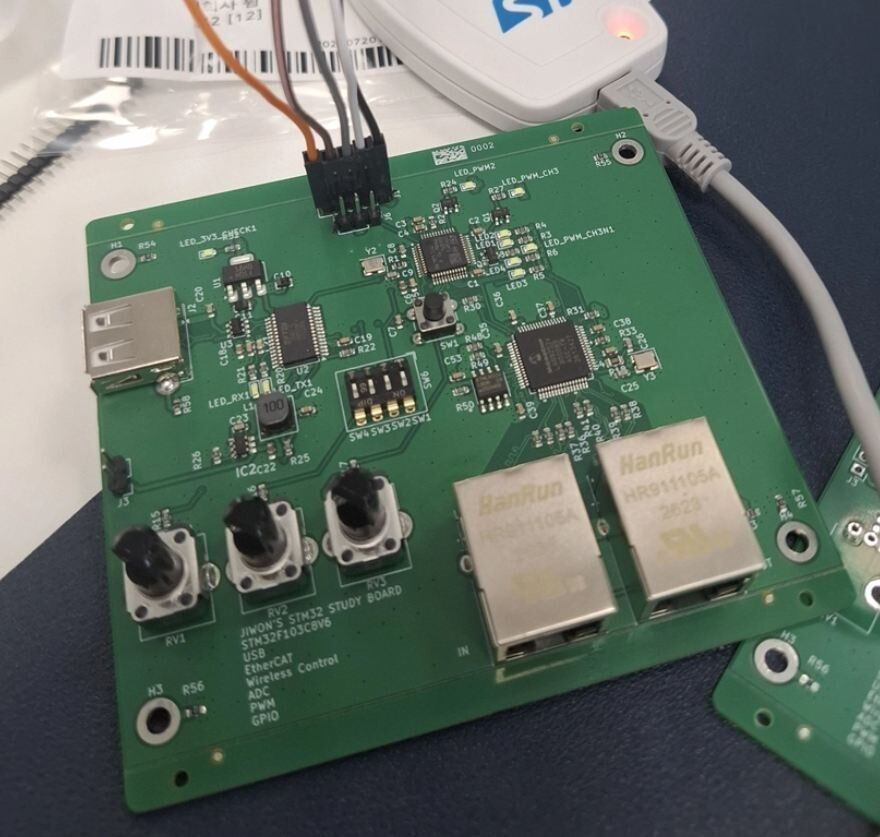
| 2026 | Tool-changer integrated board |
| 2026 | 6-axis research and teaching arm systems on our controller, for universities |
| 2025 | Control module for a fire-fighting robot ground station |
| 2024–2025 | Deep-learning robotic sorter, two stages |
| Ongoing | Painting control system and food-processing automation, in progress |
§W7 Next stepEngineer to engineer