One stack · three ways in
Pick the door that matches your end value.
Each service is written as a spec sheet: who it is for, what you get, what we need from you and how it ends. Every one starts with a fixed-scope step that measures your own baseline.
Ship your robot to the customer site with timing you can prove.
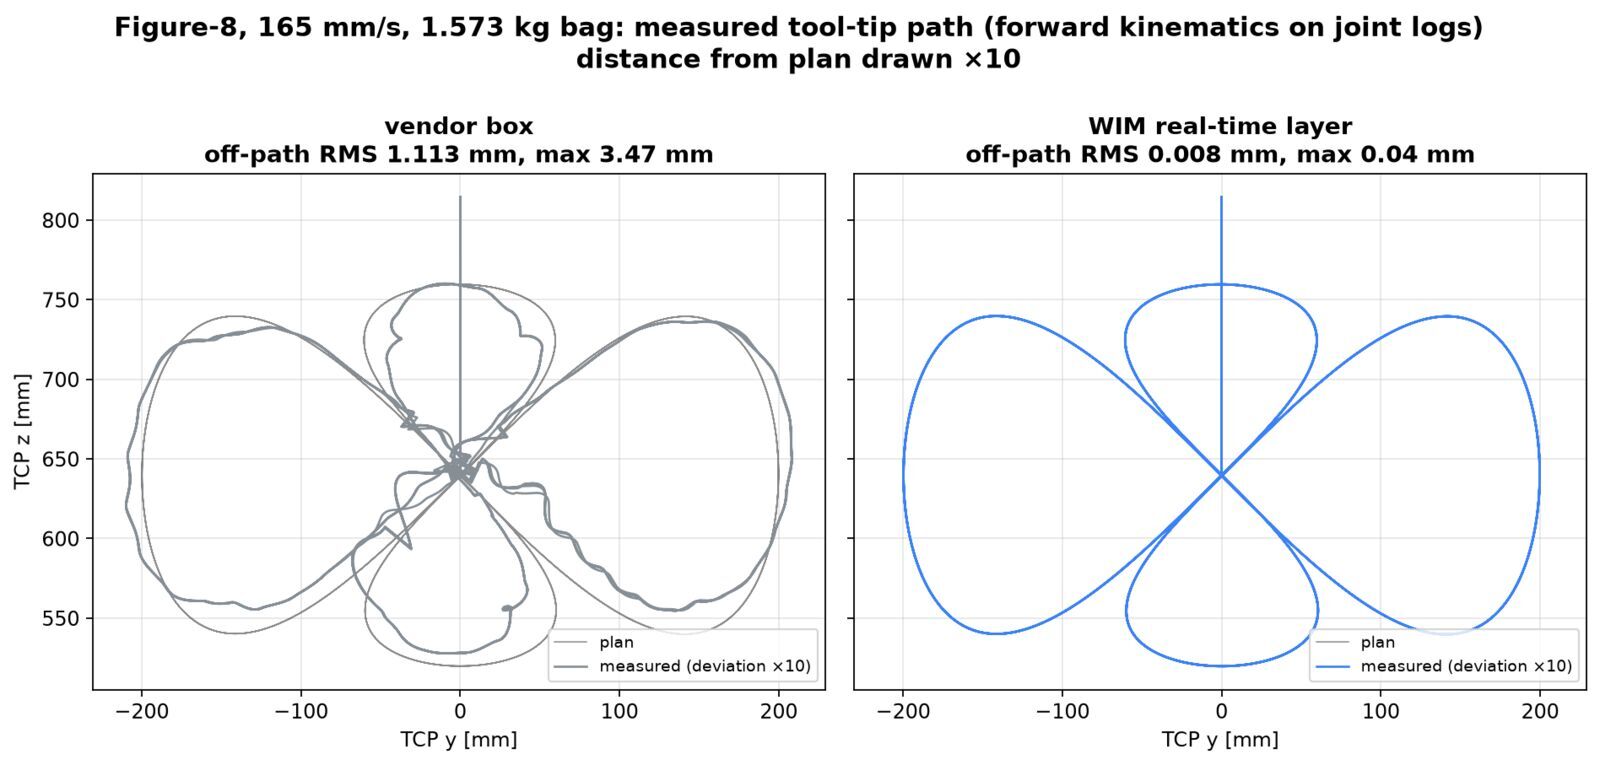
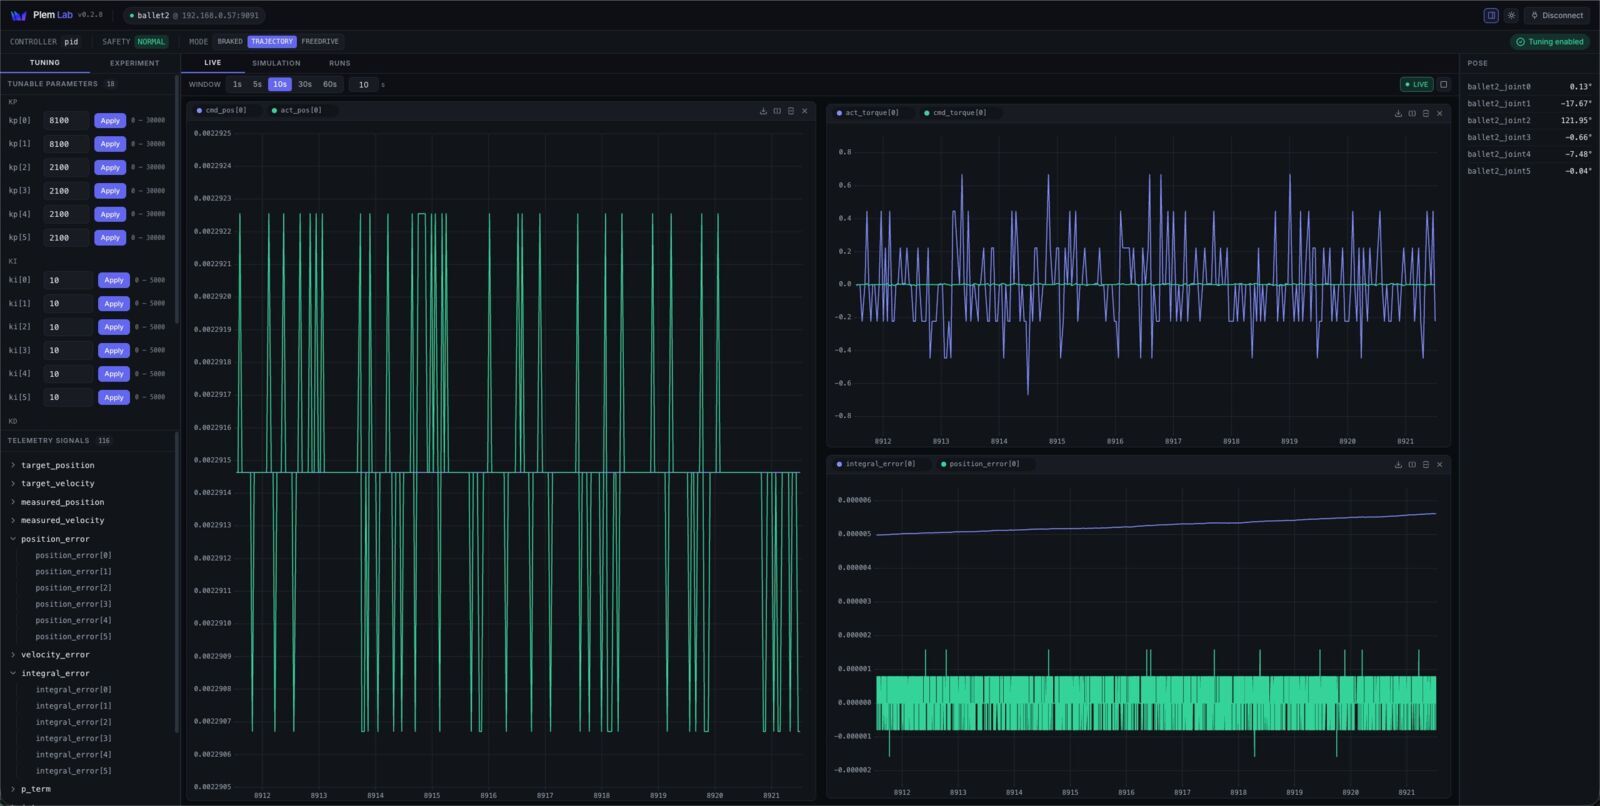
Your model outputs actions at 10 to 30 Hz. Your robot needs a stable command at 1 kHz. PLEM is the layer in between. Our engineers put it on your hardware and tune it with your team.
| Spec | Detail |
|---|---|
| For | Head of robotics, deployment or field engineering lead, founding engineer at a foundation-model, humanoid or mobile-manipulation company |
| Trigger | A paid pilot or customer deployment is coming and the arm still shakes, lags or misses deadlines on the real hardware |
| You get | Real-time audit of your Jetson (kernel, CPU and IRQ isolation, thread priorities) · action streaming, delay compensation, trajectory shaping, IK · drivers and ros2_control plugins for EtherCAT, CAN-FD, RS-485 actuators · vendor-SDK bridges · bring-up with your engineers |
| First step | The 3-day bring-up: day 1 we measure where the time goes, day 2 PLEM goes on your Jetson, day 3 your policy runs at 1 kHz with a before/after report |
| Deliverable | Timing report with raw logs, integration code in your repo, PLEM real-time layer licensed per robot with updates |
| We need | Robot or a copy of it, remote access or a 60-second log, one engineer on your side |
| Handover | Your models, data and application code stay yours. PLEM is WIM technology, licensed per robot |
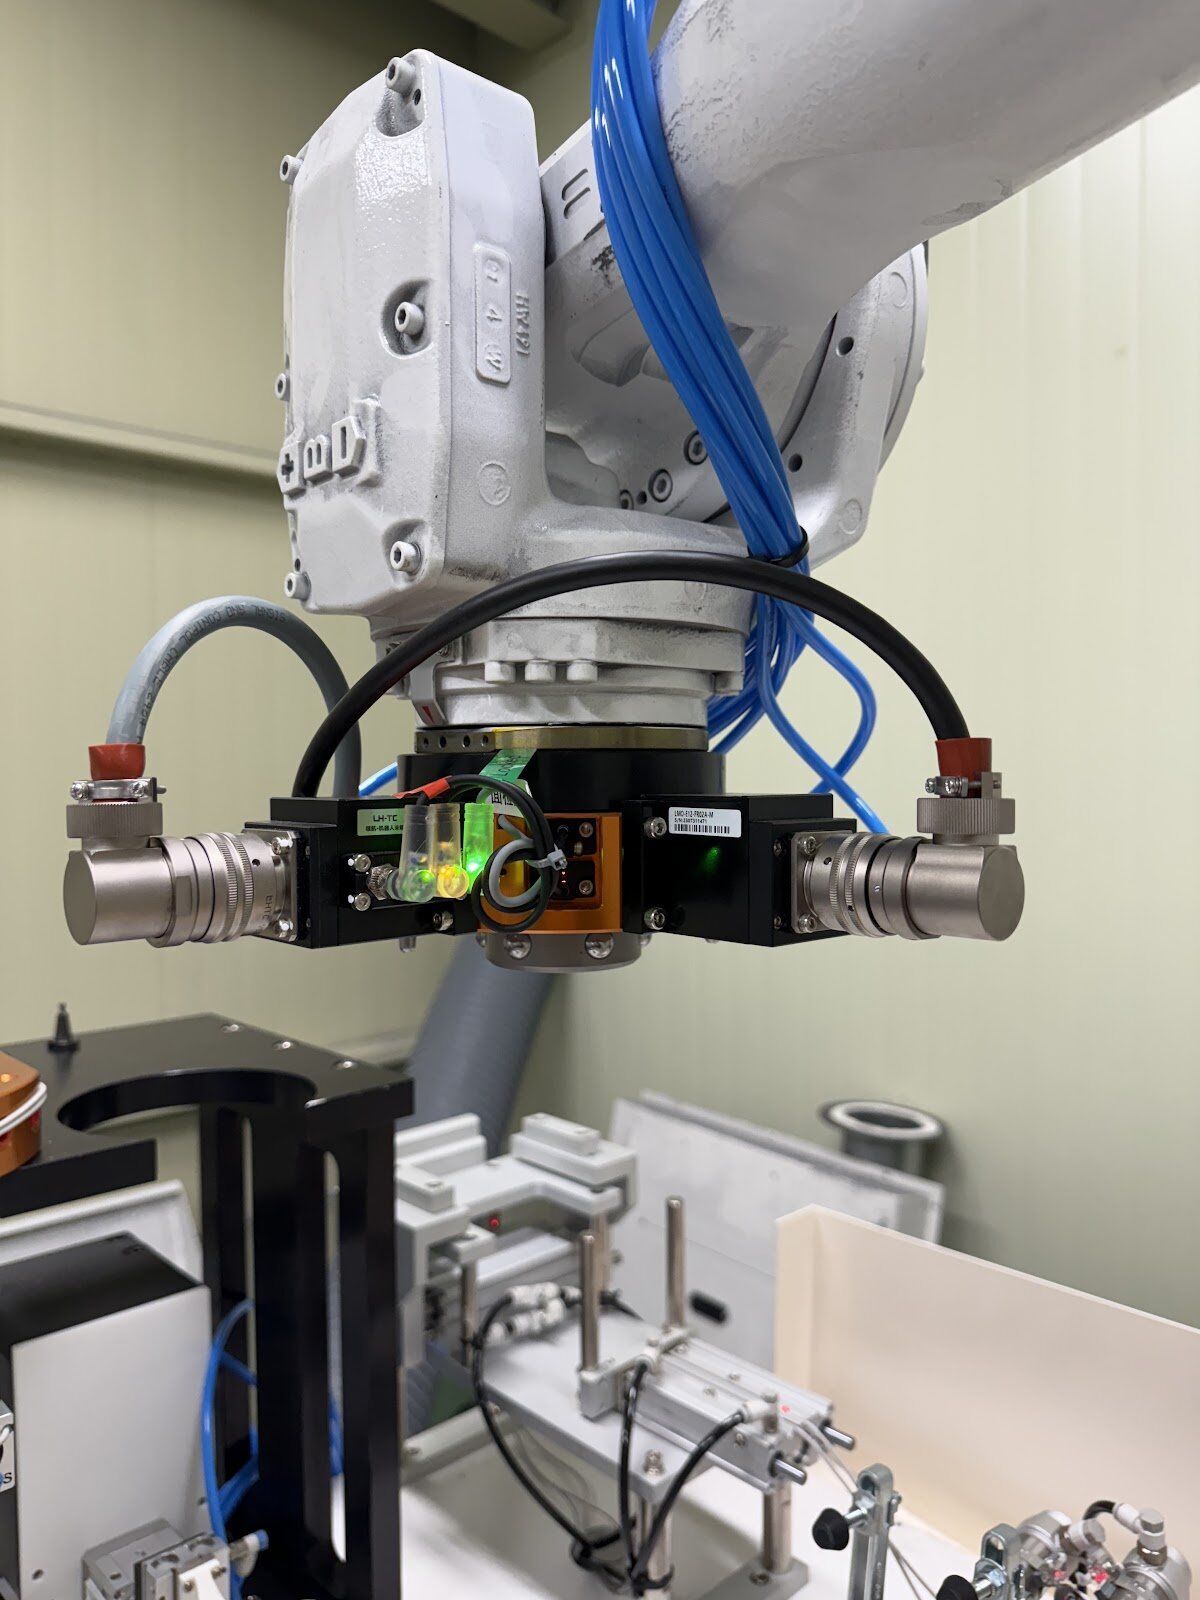
Say yes to the AI cell your customer asked for, and hit your FAT date.
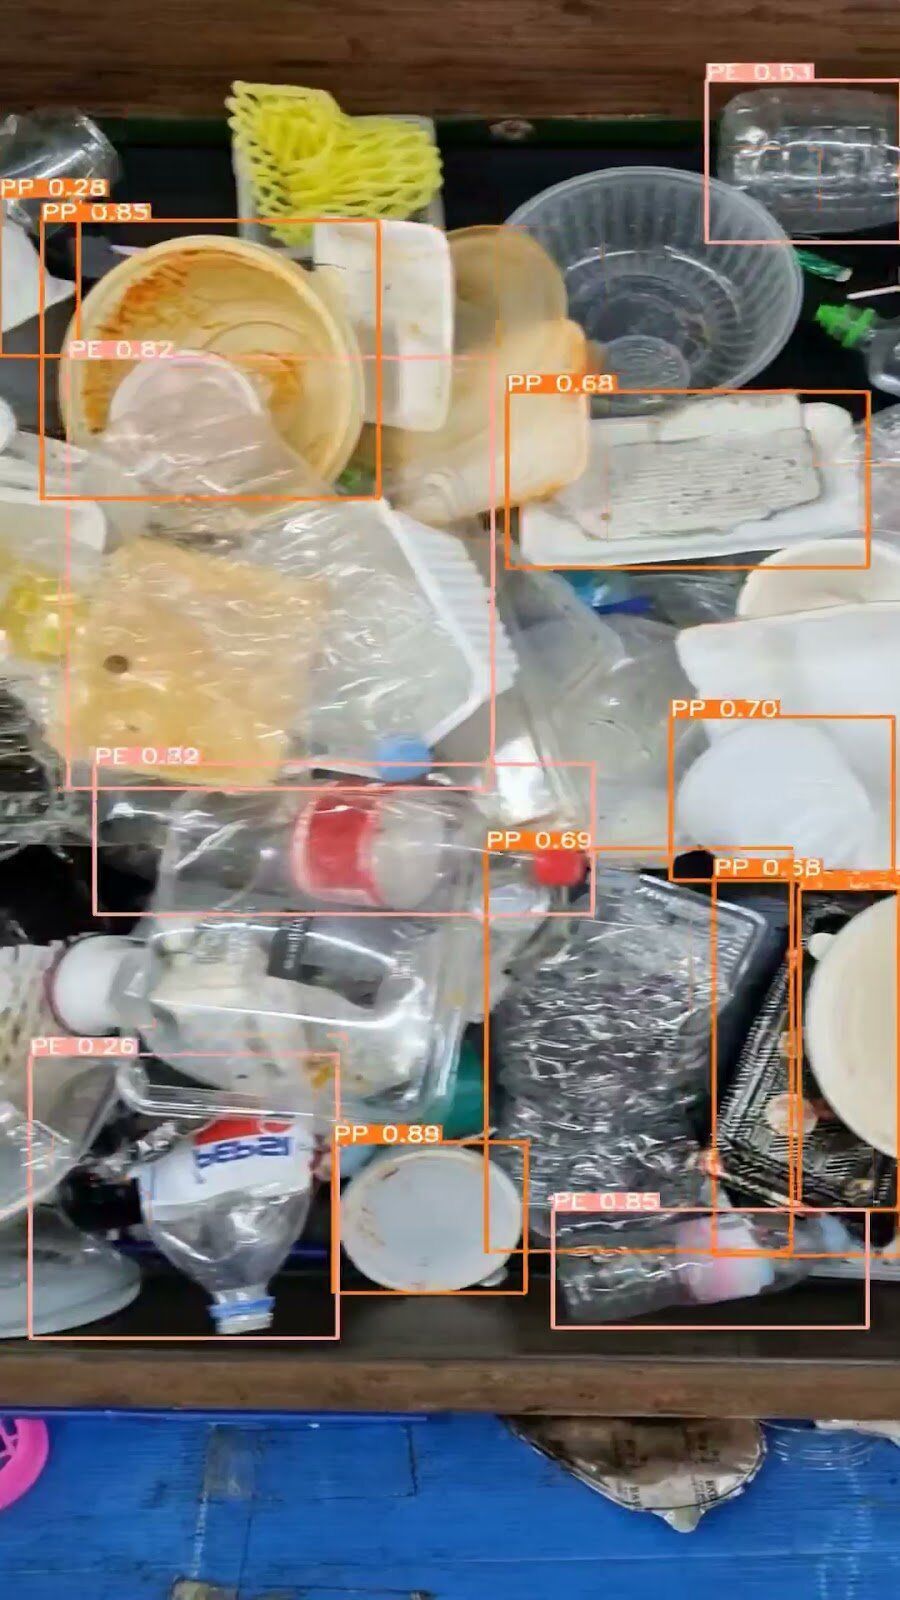
We take the one high-speed, vision-guided or multi-robot segment the standard cell cannot hold, and leave the rest on your customer's standard. You keep the customer.
| Spec | Detail |
|---|---|
| For | Machine builders, system integrators and research labs that need cells built around their equipment |
| Trigger | A customer asks for AI, vision or multi-robot work outside your standard cell, or a cell fails acceptance on timing |
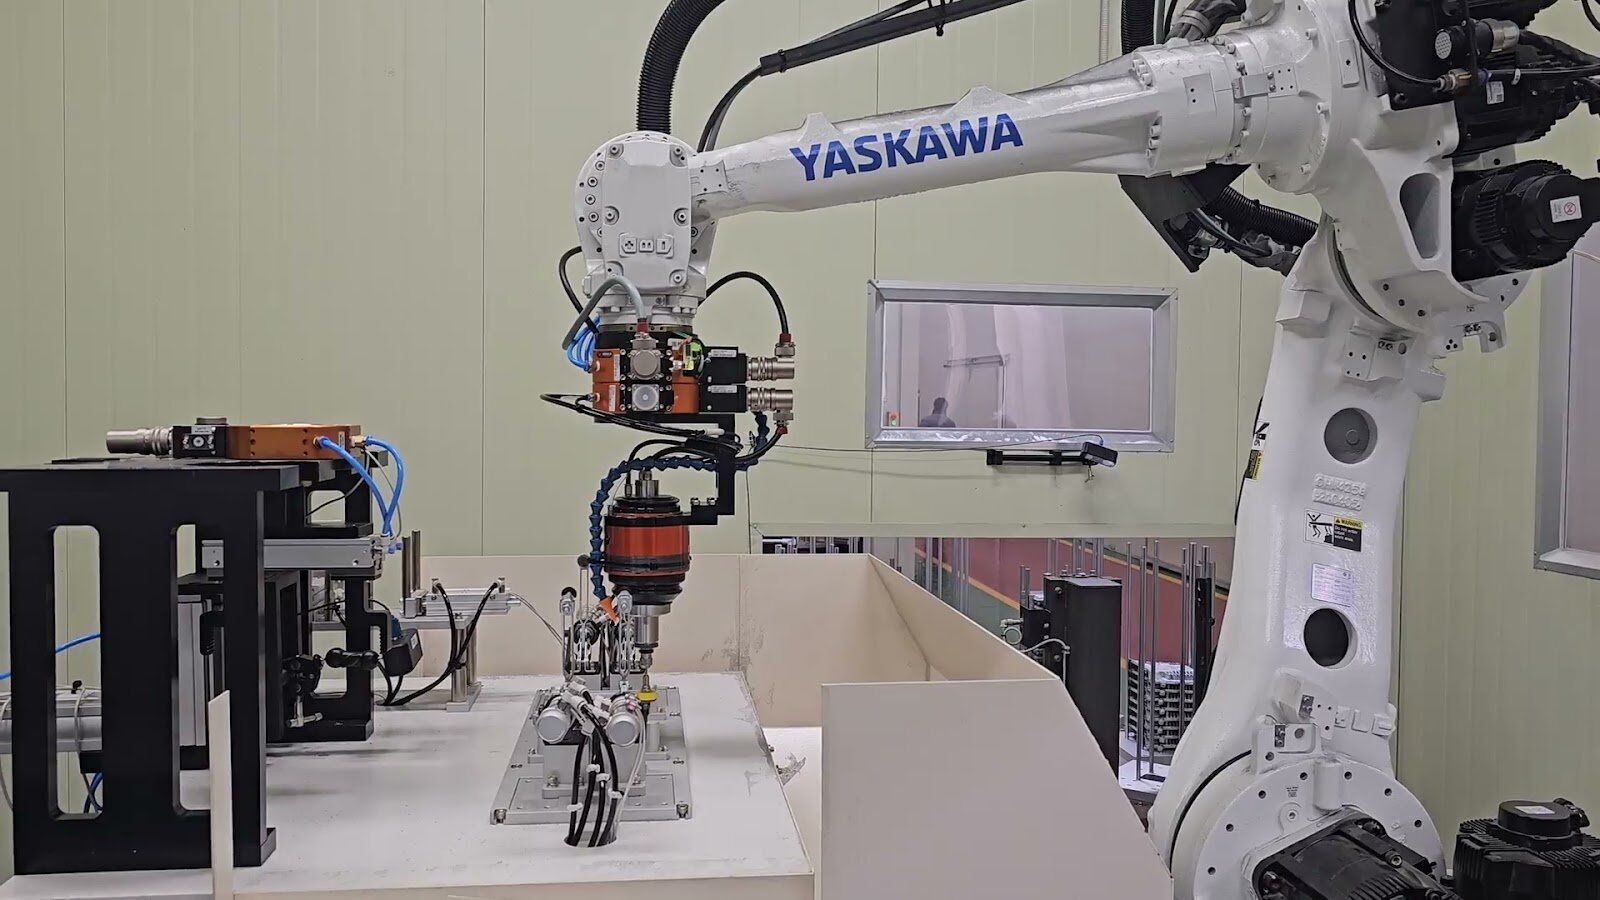
| You get | Cell design and simulation before steel · bridges to Yaskawa (MotoROS2), KUKA, collaborative arms, EtherCAT CiA 402 drives, ROS 2 · vision and grippers · PLC interface · commissioning and acceptance test · our W-RC controller where one box must run AI and motion |
| First step | Remote review of one cell, fixed scope |
| Deliverable | Design package, fixed quote, cell built to written pass criteria, acceptance report |
| Commercial | Subcontracted under your name if you prefer · milestone billing |
| On site | In the U.S., our engineers install, commission and service on site under the equipment purchase contract |
| Labs | Lab integration: research arm sets on W-RC and PLEM with live tuning and 100+ telemetry signals |
We turn your line into physical AI.
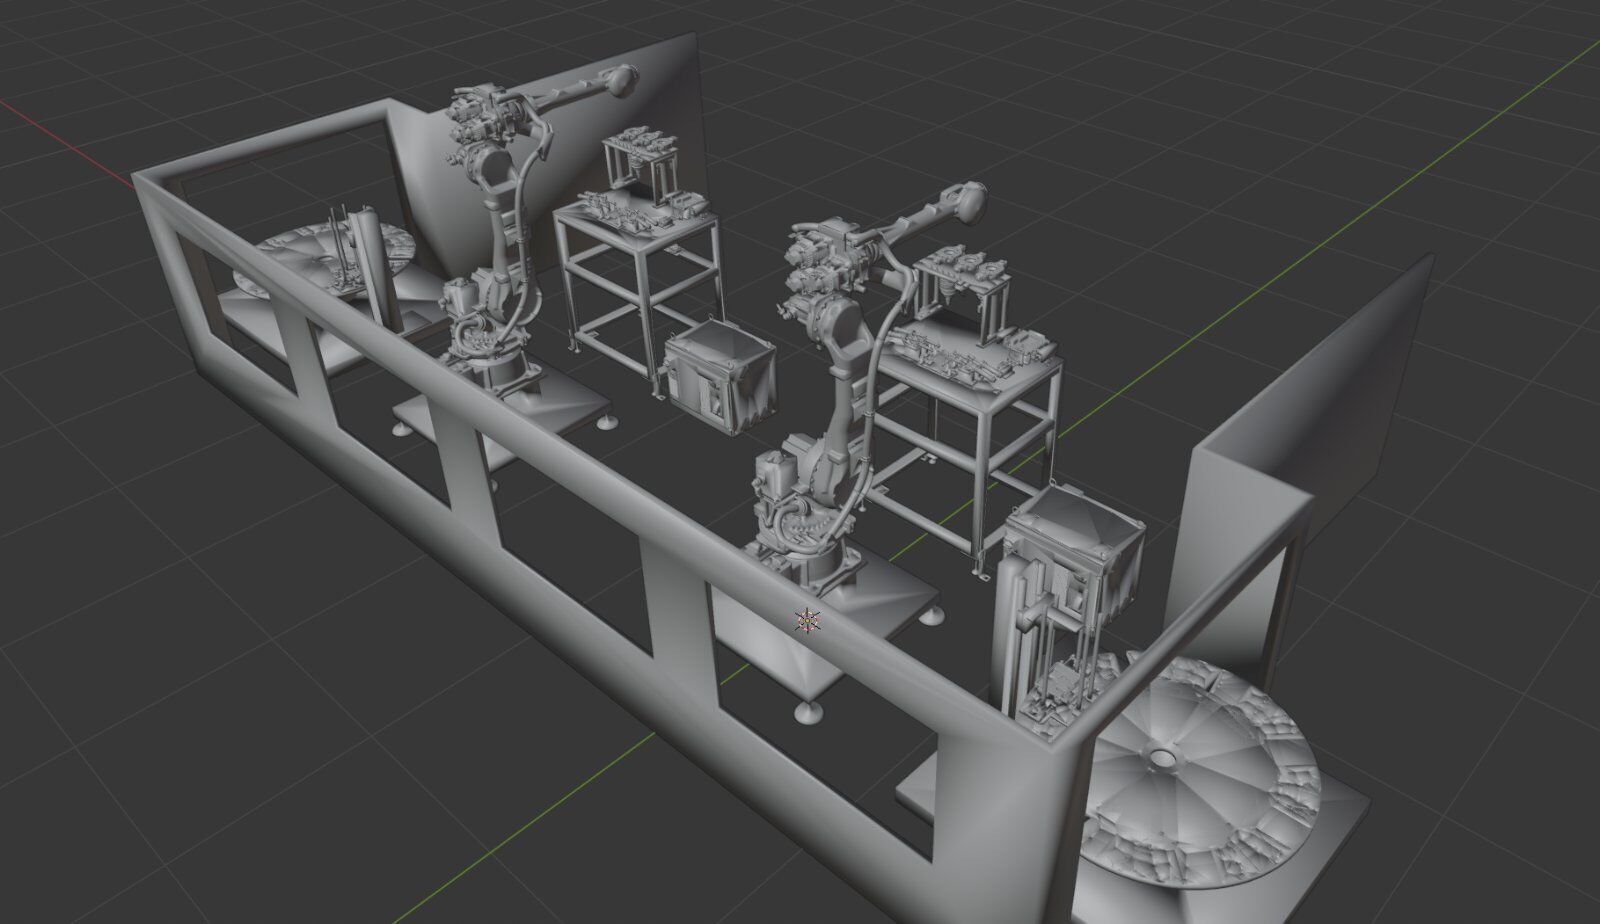
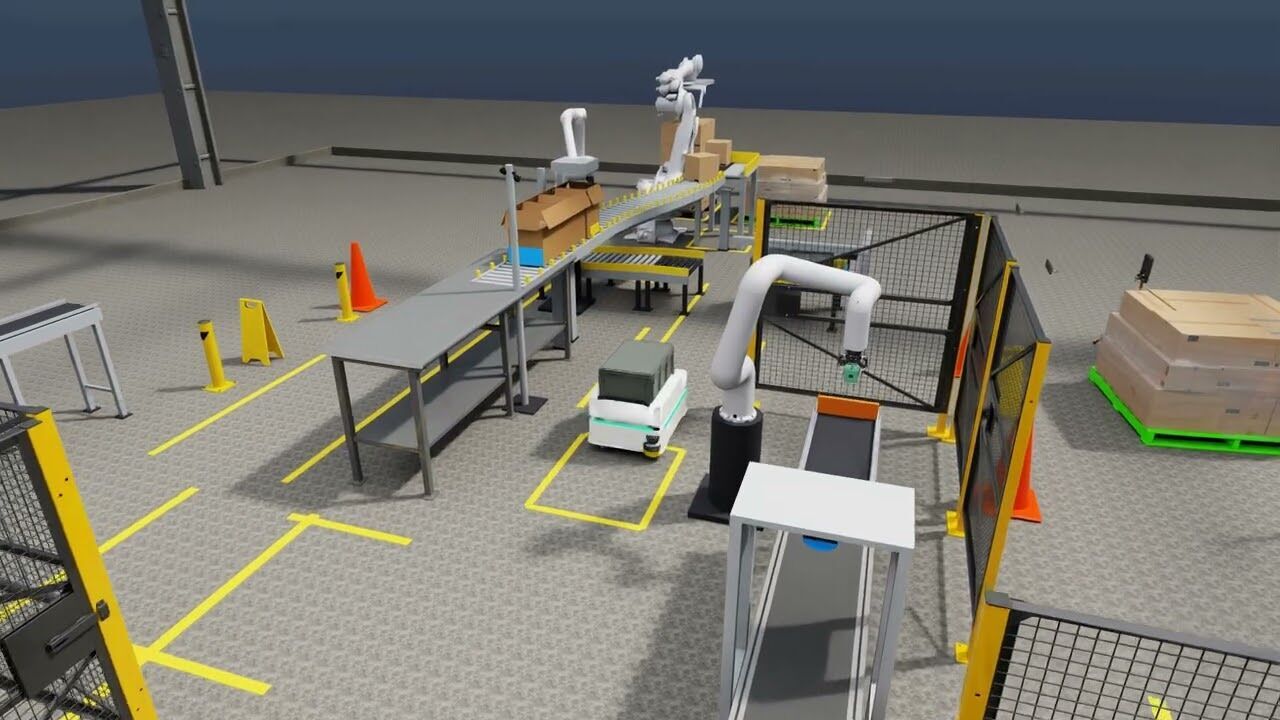
Start by knowing what one station costs you per shift. We time the station you worry about, simulate the cell you would buy, and give you a phased plan with a cost and payback band. If we build it, the fee is credited to the order.
| Spec | Detail |
|---|---|
| For | Plant managers, operations and manufacturing engineering leads, owners of mid-size plants |
| Trigger | One station limits shipments, hiring for it is hard, or a robot bought earlier never reached its rate |
| You get | Station timing (waiting, stops, rework) · process study · simulation of the proposed cell (reach, layout, interference, cycle) · phased plan with cost and payback band · list of what to buy and what to keep |
| First step | Station assessment, fixed scope. The fee is credited to the build |
| Deliverable | Baseline report with your numbers, simulated cell, phased plan you can take to budget |
| Build | With your integrator or with us, on your existing robots and PLC where possible |
From study to production, one team.
You can enter at any phase. The engineers who measured your baseline are the ones who commission the cell.
| Phase | Work | Service | Exit |
|---|---|---|---|
| 0 · Study | Process study, simulation, feasibility | Consulting | Baseline report · go / no-go |
| 1 · Prototype | Bring-up on your hardware or a lab cell | FDE · Consulting | Design review · fixed quote |
| 2 · Pilot | One cell, in your workflow, measured before and after | FDE · Integration | Pass criteria met |
| 3 · Production | Commissioning, acceptance, training, support | Integration | Acceptance report |
Fixed scope first
Every engagement starts with a time-boxed, fixed-price step. Scope, schedule and price come before any commitment to more.
Milestone billing
Advance on contract, interim on design or installation milestone, final on acceptance.
Ownership in writing
Work built for your application is yours, handed over with documentation and training. PLEM and the W-RC controller are licensed per robot, with updates included.
Weekly evidence
Measurements, not status reports: what we changed, what moved, what is next.
Time zones
For U.S. Pacific teams, our morning overlaps your afternoon; the rest runs async, plus site visits planned into scope.
What we need from you
Process and equipment details, one point of contact, and access for measurement and acceptance.
Do you replace our robots or controllers?
We start from what you have. Where a robot or cell needs AI inference and real-time motion together, our controller, a Jetson running PLEM, does both on one board.
Which robots and fieldbuses have you worked with?
EtherCAT (CiA 402) drives, CAN-FD and RS-485 actuators, and commercial arms through their own interfaces, including Yaskawa controllers through MotoROS2 and collaborative 7-axis arms through their streaming APIs. Ask us about yours.
Can you work on site in the U.S.?
Yes, for defined engagements. Most work starts remotely and site visits are planned into the scope. In the U.S., installation and service on site are tied to the equipment purchase contract.
How fast can you start?
A remote baseline can start as soon as we have logs. Send them with your first message.