WIMRobotics
§00 SummaryDOC WR-SITE-01 · REV 2026-11 · US / KR

Physical AI infrastructure

Bring your robot. Build physical AI with us.

We build the Android of robotics. Everything below your application and above the chip is ours, so you never have to touch control.

FIG 0 · Where we sitBelow the application · above the chip
Your applicationYOUmodels · policies · tasks
PLEMWIM · 1 kHz
Real-time OSEtherCATDrivesKinematicsCalibrationLow-level control
One NVIDIA JetsonCHIPAI inference + 1 kHz control on the same board
Your robot · arms, humanoids, cells
WHAT WE SELL The controller (Jetson + PLEM) and its license. Forward deployed engineering and system integration put it on your floor.
±4.1µs
cycle jitter · 12 axes · 1 kHz
LTA LR500172603E
−77%
path error on a 7-axis arm
Field test · California · Oct 2026
3yrs
on one machining line
Repeat orders 2024–26
30+
sites running our controllers
Delivered
§00b Before / AfterGrey = before · orange = with WIM
Bring-up
6–12 months
3days
to a running control stack
Hardware
3–5 computers
1Jetson
runs the AI and the 1 kHz loop
Real-time
358 µs worst case
15µs
20× steadier loop · Jetson AGX Orin
Operation
Teach pendant
Chat
tell the robot the task in plain language
§00c The 3-day bring-upOur first step with every team

Three days, on your own hardware.

Day 01

Measure

We find where the time goes.

You getTiming baseline, raw logs
Day 02

Install

PLEM goes on your Jetson, tuned.

You getA robot that holds 1 kHz
Day 03

Run

Your policy drives the robot.

You getBefore / after report · code in your repo · license quote
§01 ProblemWhy projects stall

Most robot projects stall between the demo and the second shift.

If you build robots or AI

The policy works in the lab and stutters on the customer's arm.

If you integrate cells

The customer wants an AI cell. The PLC can't hold it.

If you run a factory

The station limits shipments, and nobody has measured why.

§02 StakesField test · San Francisco Bay Area · Oct 2026

77% less path error on an arm we didn't build.

Same arm, same computer, same paths. Only the command timing changed.
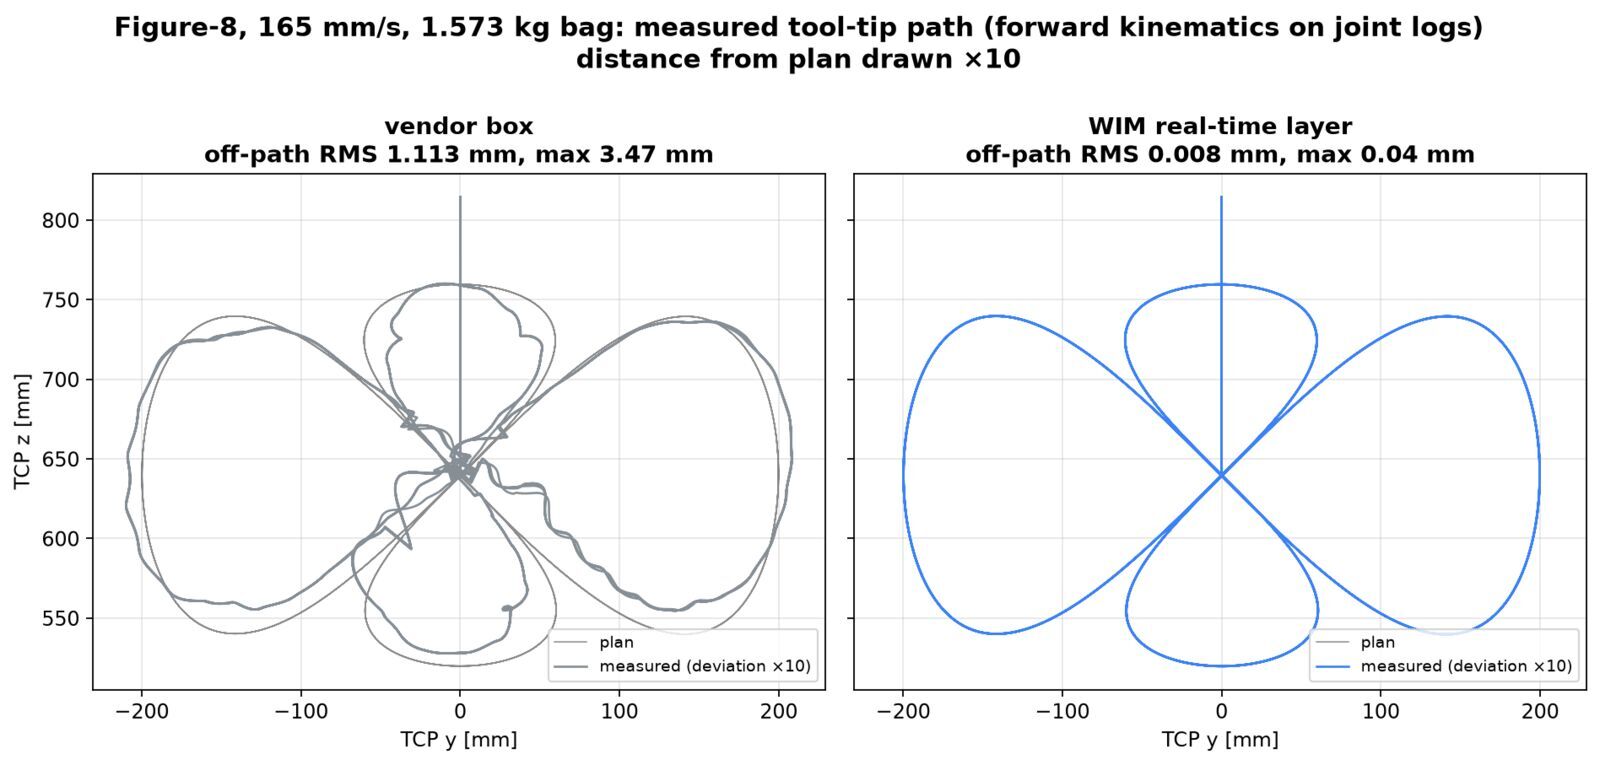
FIG 1 · Tool-tip path error, RMSmm · lower is better
0123mm Figure-eight165 mm/s 1.154 0.267 Weave3D path 2.58 0.576 Stress1,000 mm/s 3.25 0.86
CH2 naive streamingCH1 WIM real-time layer
SOURCE Engineering blog, "Time is a control input", 2026-10-23, with raw plots.
FIG 2 · Figure-eight tool pathbefore · after
Measured figure-eight tool path: wavering with the arm's own streaming, clean with the WIM real-time layer
−77%
path error, both test paths
0
controller errors in 30 runs

Read the full test →

§03 Choose your pathThree readers · one stack

One stack. Three ways in.

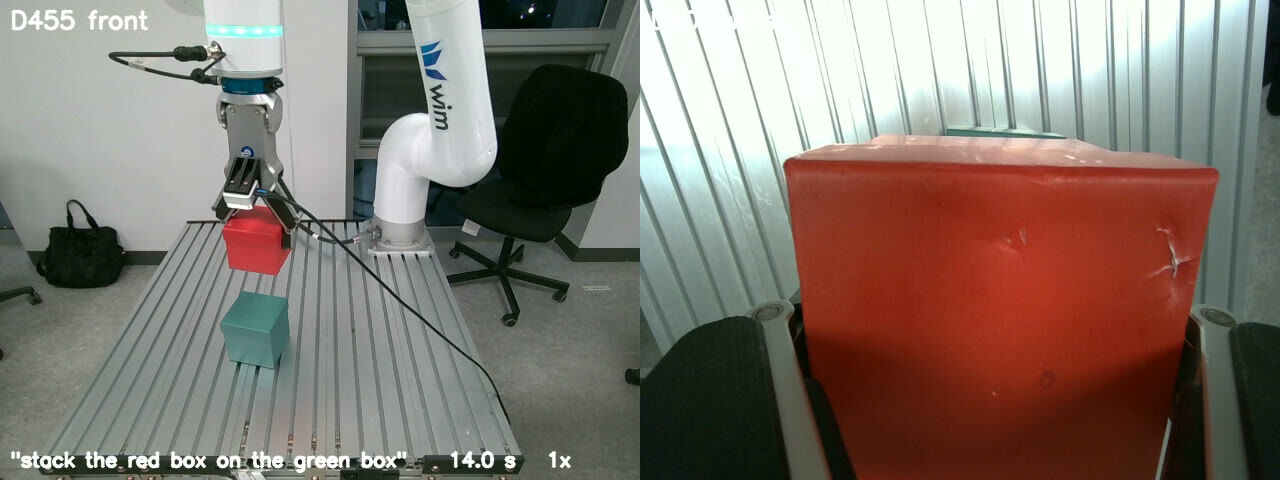
Robot arm stacking a red box on a green box from a language instruction
AI & robotics teams · Forward deployed engineering

Ship your robot to the customer site with timing you can prove.
First step

The 3-day bring-up on your robot.

Forward deployed engineering →
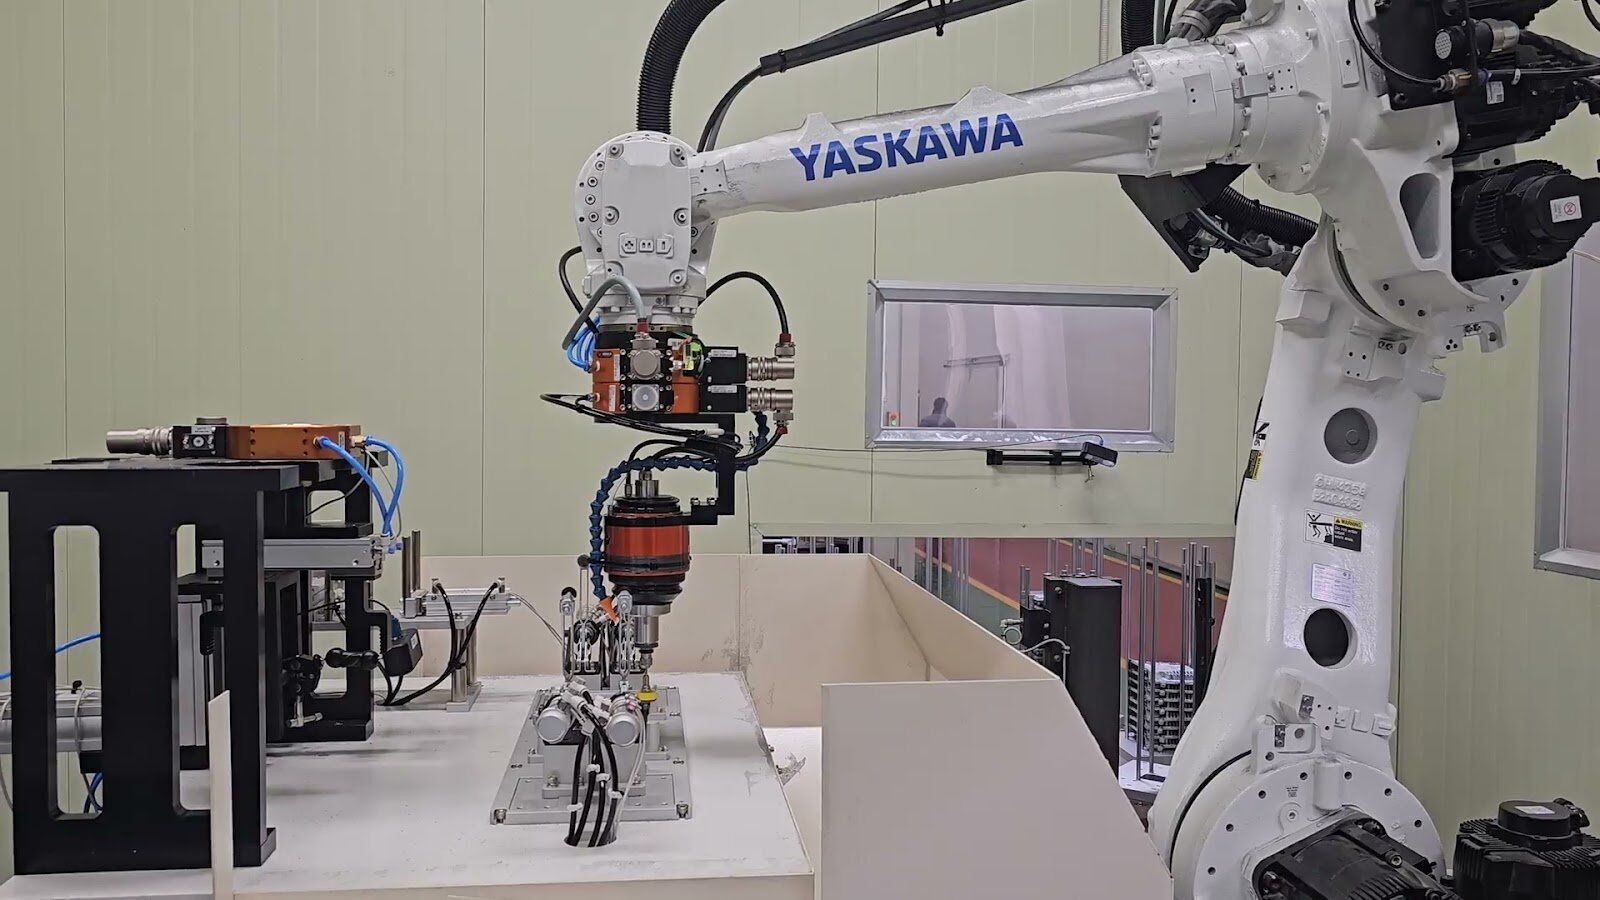
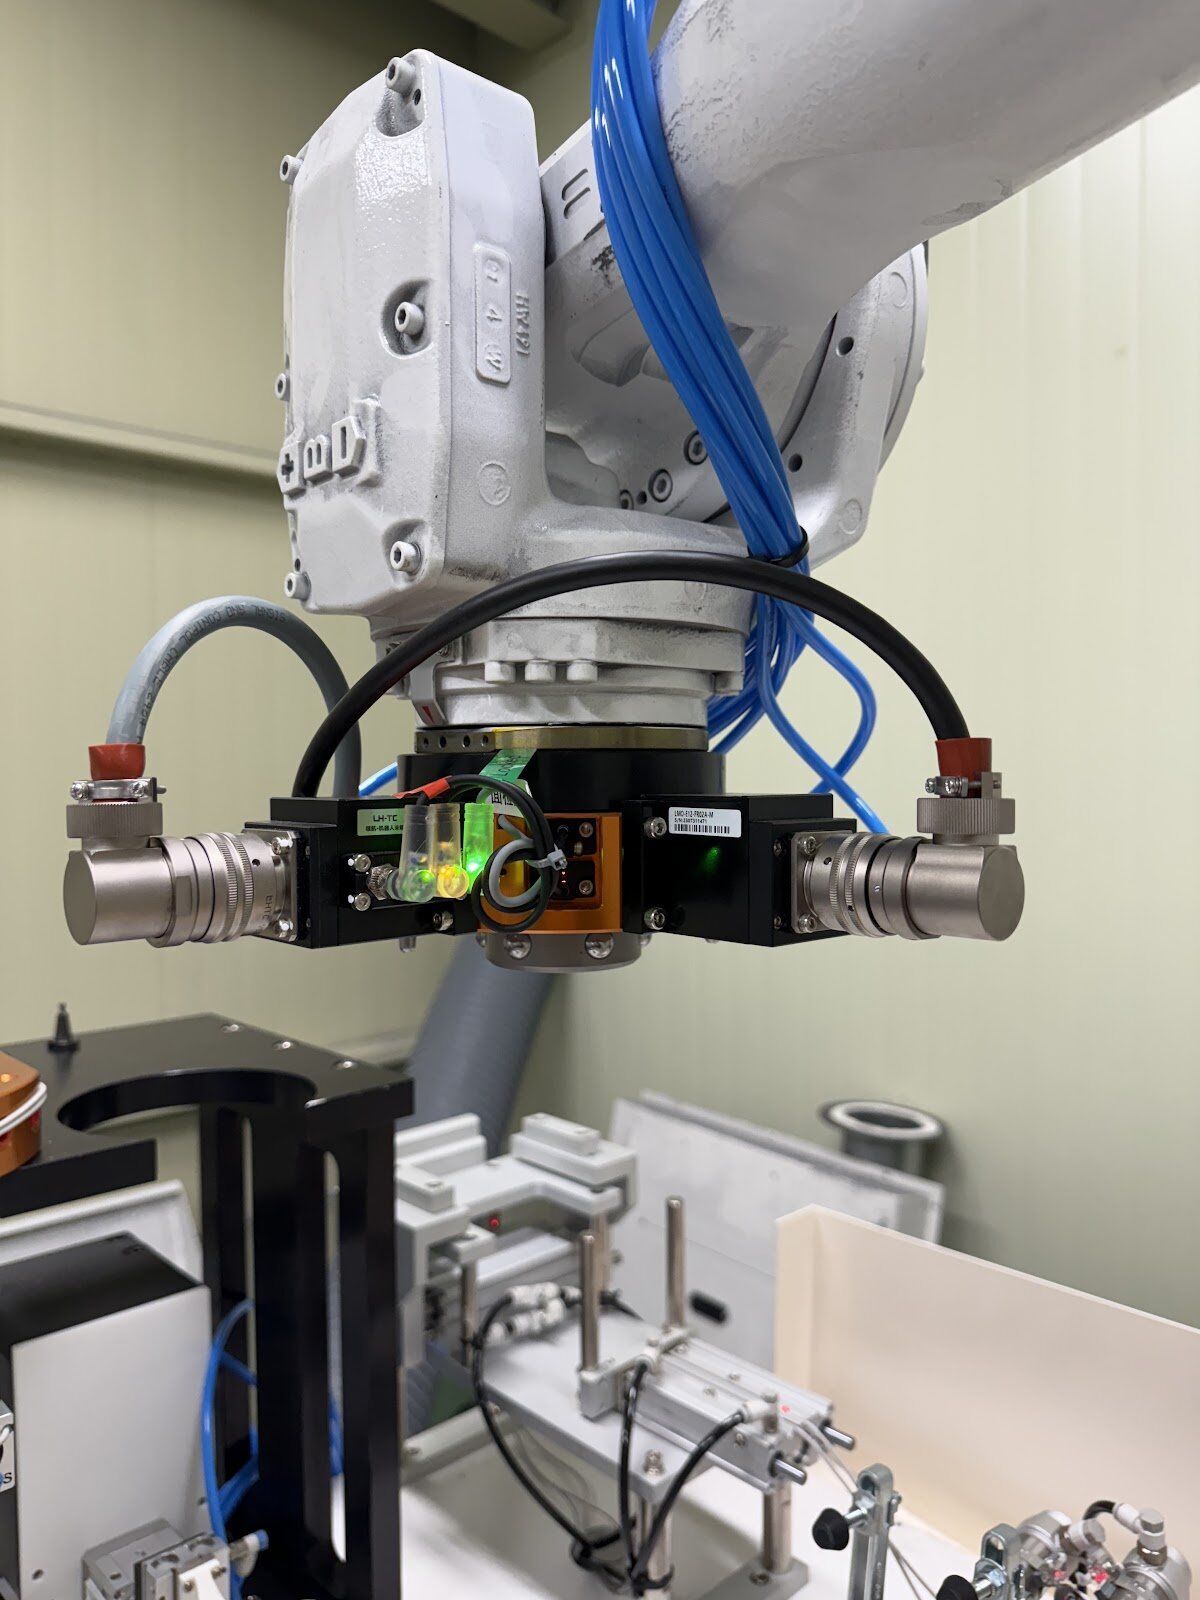
Industrial arm with a tool changer and gripper inside a machining cell
Machine builders & integrators · System integration

Say yes to the AI cell your customer asked for, and hit your FAT date.
First step

Remote review of one cell, fixed scope.

System integration →
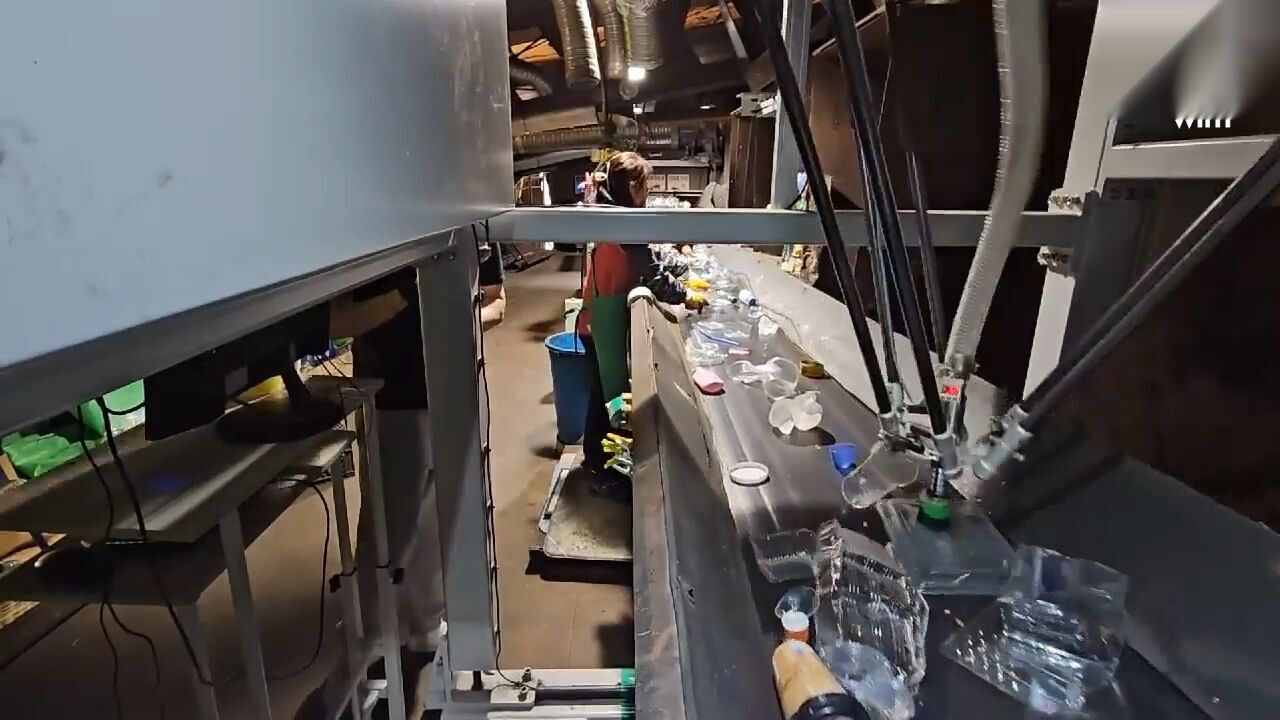
Delta robots picking over a running conveyor line
Factory owners & plant leaders · Automation consulting

We turn your line into physical AI.

First step

Station assessment, credited to the build.

Automation consulting →
§04 EvidenceEvery number with its source

Measured, not claimed.

328→3.5µs
EtherCAT clock drift on Jetson, fixed
Blog · 2026-10-10
86ms
Pi0.5 inference on Jetson AGX Thor
Measured · 2026-11
−59.5%
hand-eye calibration error, real arm
Peer-reviewed · RAS 2026
−32%
path error vs built-in PID, same arm
Video · 2026-10-21
TESTED

LTA LR500172603E

12 axes at 1 kHz · cycle jitter ±4.1 µs · Mar 2026

TESTED · PASS

KOTCA KST-25-236

Control-loop latency and periodicity · Oct 2025

TESTED

FCC Part 15B · ICES-003

W-RC controller · Class A · Jul 2026

RESULTS PENDING

ISO 9283 accuracy, KTL

Pose and distance · run 2026-11-05

Patents KR 10-2729148 · KR 10-2717166U.S. patent pendingRobotics and Autonomous Systems (2026)NVIDIA Inception Grand Challenge 2026 Top 10

All test data and conditions →

§06 MechanismWhat we actually do

One Jetson runs the AI and the 1 kHz control loop.
Cameras + languagethe task
Policy10–30 Hz
Real-time bridge→ 1 kHz
Real-time control1 kHz
EtherCATµs sync
Your drivesthe robot moves
Language task → policy → 1 kHz EtherCAT
One Jetson, several arms
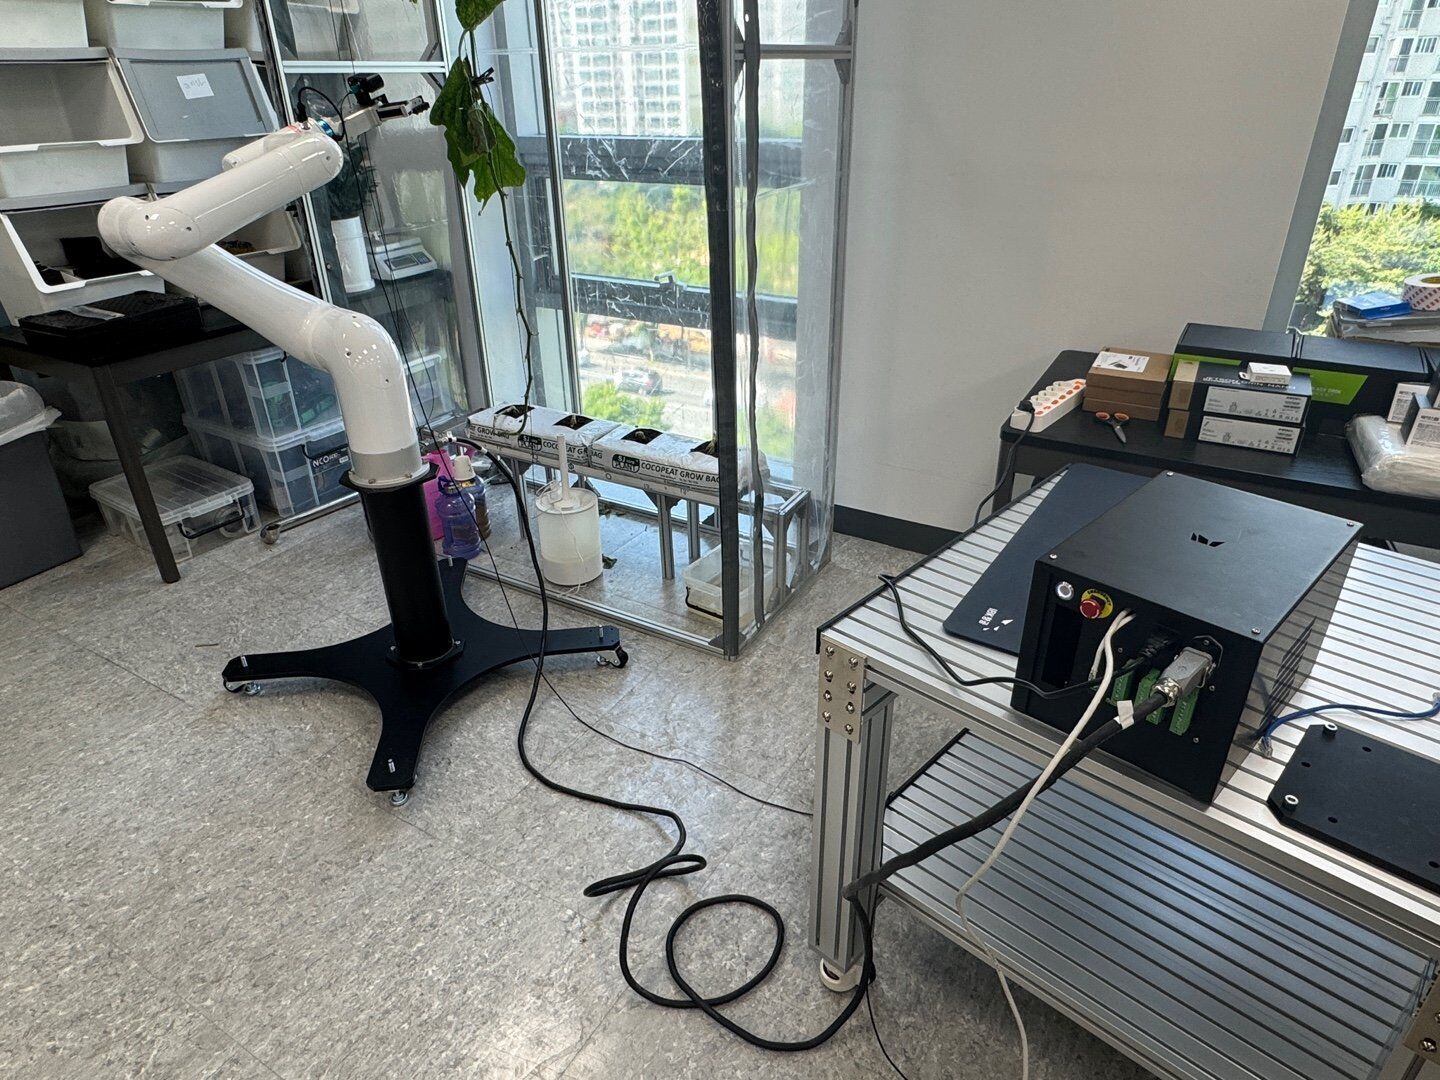
W-RC controller box cabled to a six-axis collaborative arm on a lab bench
W-RC controller · Jetson + PLEM
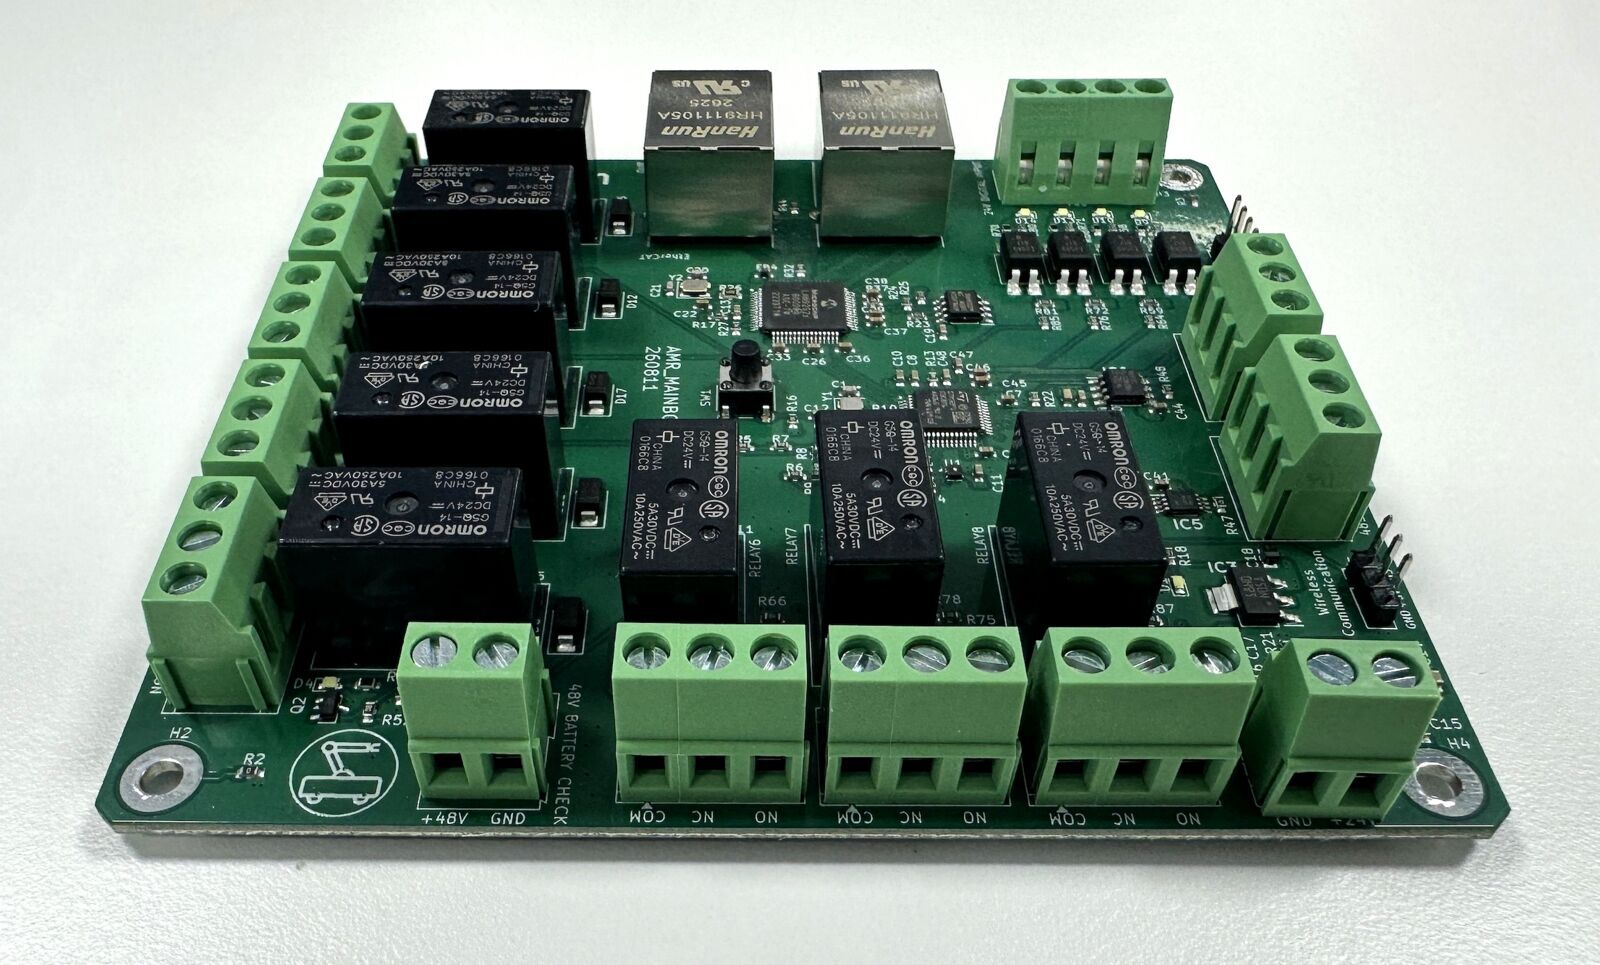
WIM-CB100 EtherCAT slave board
WIM-CB100 · our EtherCAT board

How the stack is built and tested →

§07 ProcedureHow a project runs

Measure first. Then build. Then keep improving.

Every step ends with a written go / no-go. You can stop after any of them.

01

Baseline

Your robot, cell or station, measured.

Go / no-goBaseline report
02

Design & twin

The cell, in simulation first.

Fixed quoteDesign package
03

Pilot

One cell against written pass criteria.

Go / no-goBefore / after measurement
04

Production

Commissioning, acceptance, training.

Signed offAcceptance report
05

Improve

Retuning as parts and volumes change.

Per contractPeriodic measurement
§08 RiskWhat we take off your plate

Built to fit what you already run.

Your equipment stays.

Yaskawa · KUKA · EtherCAT drives · ROS 2

You approve every step against numbers.

Pass criteria written first

Fixed scope, priced before we start.

No open-ended hours

Your integrator keeps the customer.

We subcontract under your name

Your models, data and code stay yours.

PLEM licensed per robot, updates included

Third-party tested.

Loop timing · 12-axis jitter · EMC
§08b A note from the founderWoojin Jun · Founder & CEO

Nobody should have to think about control to build physical AI.

We started as an AI team. The moment we tried to put our models on a real robot, we hit a wall that had nothing to do with AI: real-time kernels, EtherCAT, drives, kinematics, calibration. Nobody sold that layer, so we built it.

That layer is PLEM, and it runs on a single Jetson. I call it the Android of robotics.

How we deliver it is closer to Palantir. The software is the product. Our engineers go forward, onto your robot and your floor, and stay until it runs. Then you build the next one yourself, on our stack.

If your robot works in the demo and shakes at the customer site, send me the log.

§09 FootprintUS · KR

WIM Robotics Inc. in the U.S. Engineering in Daegu, Korea.

Pacific afternoon is Korean morning, so work moves every day.

United States

WIM Robotics Inc.

Delaware · your point of contact

Headquarters

WIM Corp., Daegu, Korea

Engineering · test lab · controllers and boards

On site

Your floor

Install, commissioning and service under the equipment purchase contract

§10 Field logMost recent first
2026-11-07Measure

Pi0.5 on Jetson AGX Thor, 86 ms per inference

2026-11-05Test

ISO 9283 accuracy test with KTL on our controller

2026-11-02Video

Dual-arm handover on a humanoid upper body

2026-10-23Post

Time is a control input: the 7-axis arm field test

2026-09-22Selected

NVIDIA Inception Grand Challenge 2026 Top 10

§11 Next stepEngineer to engineer

Send us a log, a video or a line description. We reply with where the time goes.